

Adaptive integration method based on residual accumulating surface for event-based star sensors
-
摘要:
为提高事件星敏感器在高动态条件下的星点成像质量和质心提取精度,解决传统固定时间积分容易产生星点拖尾、自适应时间积分图像发布频率不稳定以及二值事件积分图像缺少连续响应层次等问题,本文提出一种事件星敏感器残差累积表面自适应积分方法。首先,设计渐进式时空去噪方法,采用空间域快速预处理与时空域聚类精化滤除背景噪声事件。接着,通过星点椭圆形态特征分析动态调整积分事件数量,提出固定发布频率与自适应事件数量相结合的积分策略,在保证事件帧发布频率稳定的同时抑制星点拖尾。然后,构建残差累积表面,通过指数衰减递归机制对事件触发频率进行连续编码,以形成由事件触发频率和时间新近性共同决定的相对伪灰度响应。最后,采用分段线性映射将残差累积表面转换为伪灰度星图,并通过高斯拟合完成亚像素质心定位。在真实星点事件流数据集上的实验表明,在焦平面像移速度为
2272.7 pixel/s时(20°视场、1024 ×1024 探测器配置下的像移等效角速度约为44°/s),本文方法平均质心提取误差约为1.56像素,平均星对角距误差约为3.35角秒,较固定5 ms积分方法分别降低58.3%与19.1%,且在焦平面像移速度284~2273 pixel/s的宽动态范围内均保持较高的质心提取精度。本文方法能有效抑制星点拖尾并形成可用于加权质心估计的星点伪灰度响应分布,可为后续星图识别与姿态解算提供高精度星点质心信息。Abstract:To improve star spot imaging quality and centroid extraction accuracy of event-based star sensors under high-dynamic conditions, and to address the issues of star trailing caused by conventional fixed-time integration, unstable image publication rate of adaptive-time integration, and the lack of continuous response levels in binary event-integrated images, this paper proposes a residual accumulating surface adaptive integration method for event-based star sensors. First, a progressive spatiotemporal denoising method is designed, which employs rapid spatial-domain preprocessing combined with spatiotemporal clustering refinement to suppress background noise events. Subsequently, an integration strategy combining a fixed publication rate with an adaptive event count is proposed, in which the number of integrated events is dynamically adjusted through elliptical morphology analysis of star spots, thereby suppressing star trailing while maintaining a stable a stable event-frame publication rate. A residual accumulating surface is then constructed using an exponential-decay recursive mechanism to continuously encode the event-triggering frequency, thereby forming a relative pseudo-grayscale response jointly determined by the event-triggering frequency and temporal recency. Finally, the residual accumulating surface is converted into a pseudo-grayscale star image via piecewise linear mapping, and sub-pixel centroid localization is accomplished through Gaussian fitting. Experiments on a real star event stream dataset demonstrate that, under a focal-plane image-motion velocity of
2272.7 pixels/s (equivalent to approximately 44°/s for a configuration with a 20° field of view and a1024 ×1024 detector), the proposed method achieves a mean centroid extraction error of approximately 1.56 pixels and a mean star-pair angular distance error of approximately 3.35 arcsec, representing reductions of 58.3% and 19.1%, respectively, compared to the fixed 5 ms integration method. High centroid extraction accuracy is consistently maintained across the wide dynamic range of focal-plane image-motion velocities from 284 to2273 pixels/s. The proposed method effectively suppresses star trailing and forms a star-spot pseudo-grayscale response distribution suitable for weighted centroid estimation, providing high-precision star-spot centroids for subsequent star identification and attitude determination.-
Key words:
- star sensor /
- event camera /
- high dynamic scene /
- adaptive integration /
- centroid extraction
-
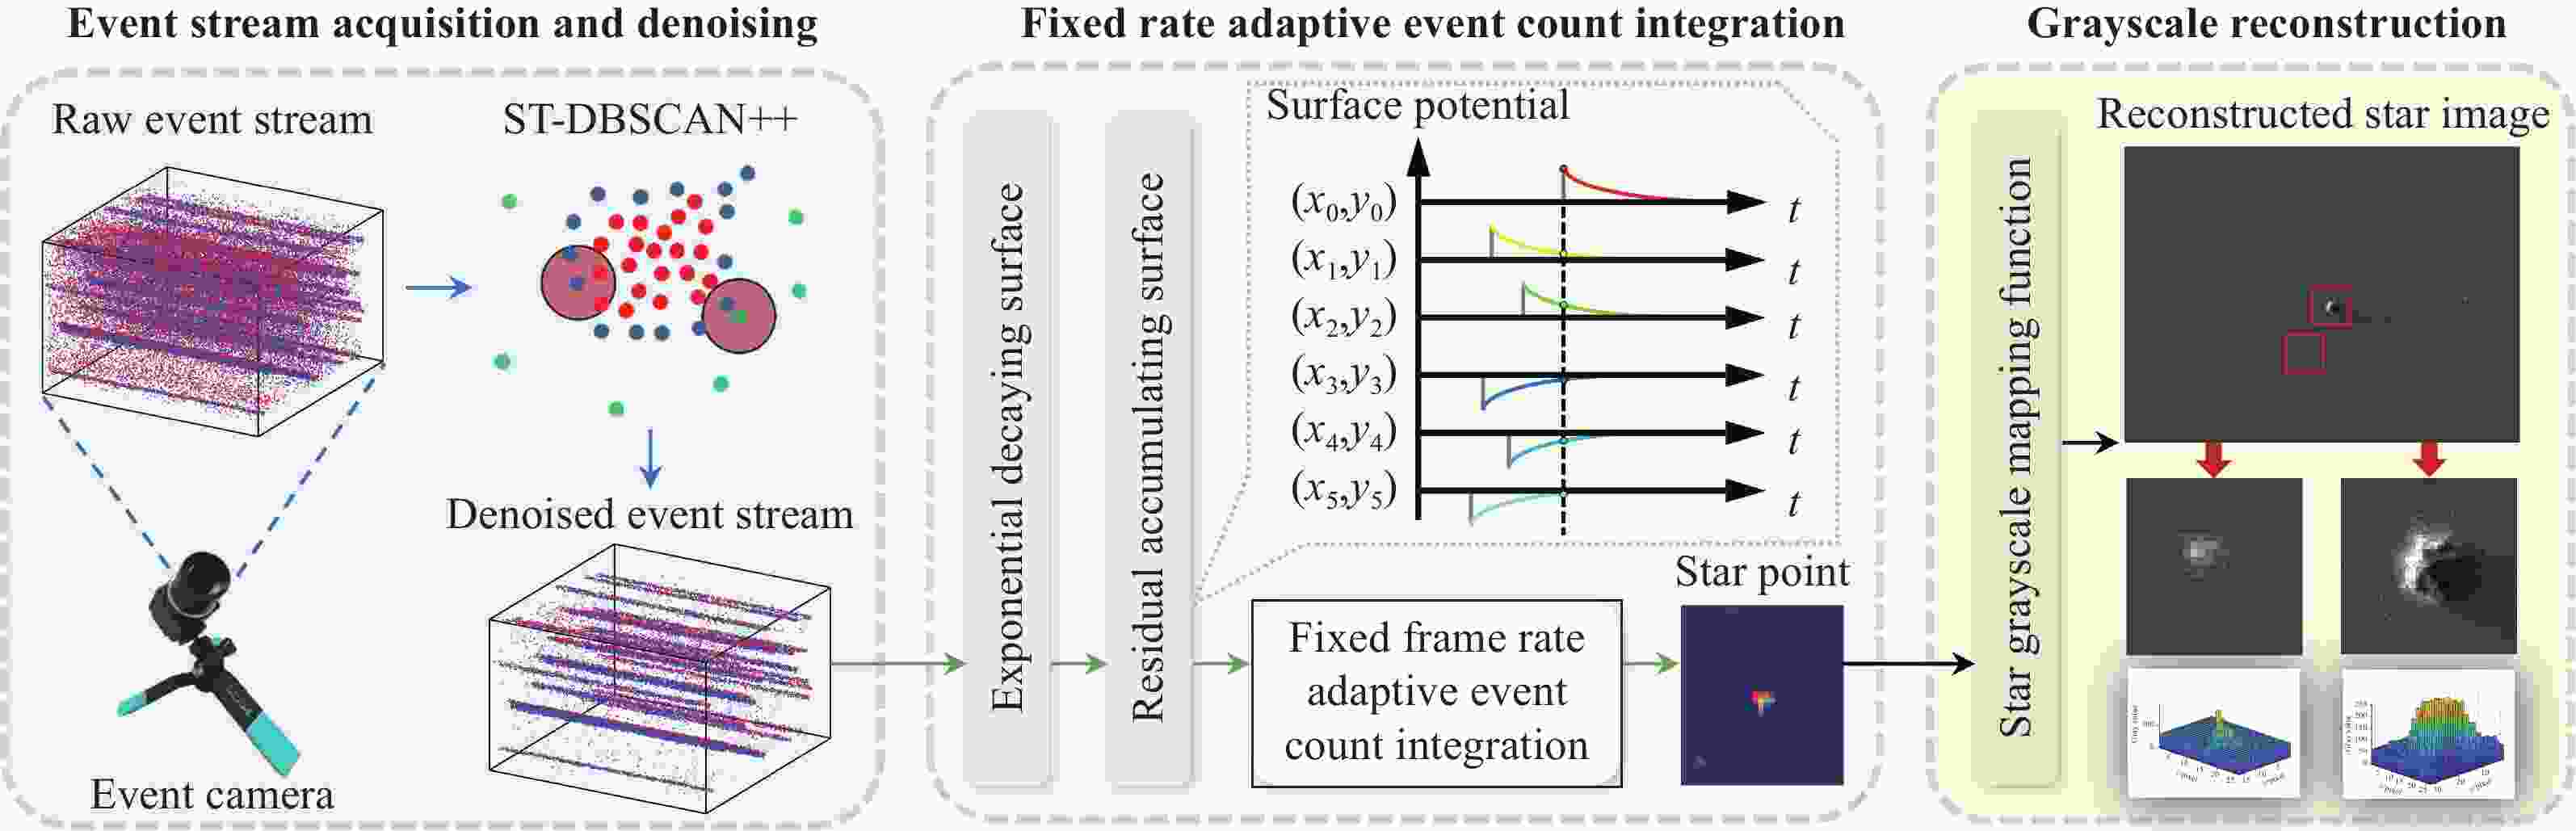
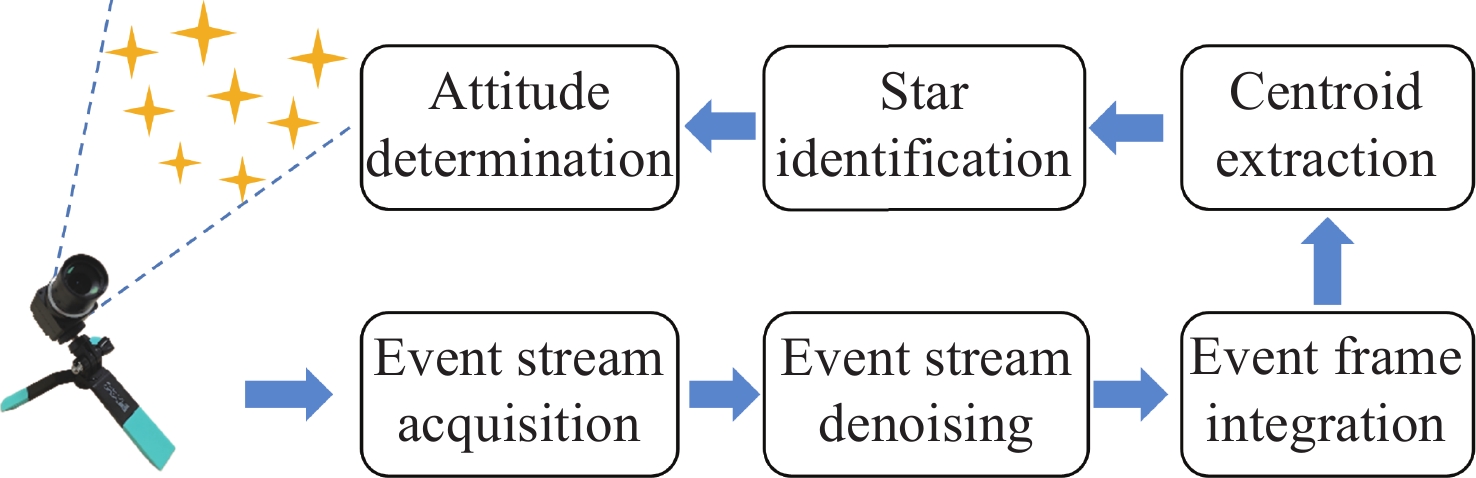
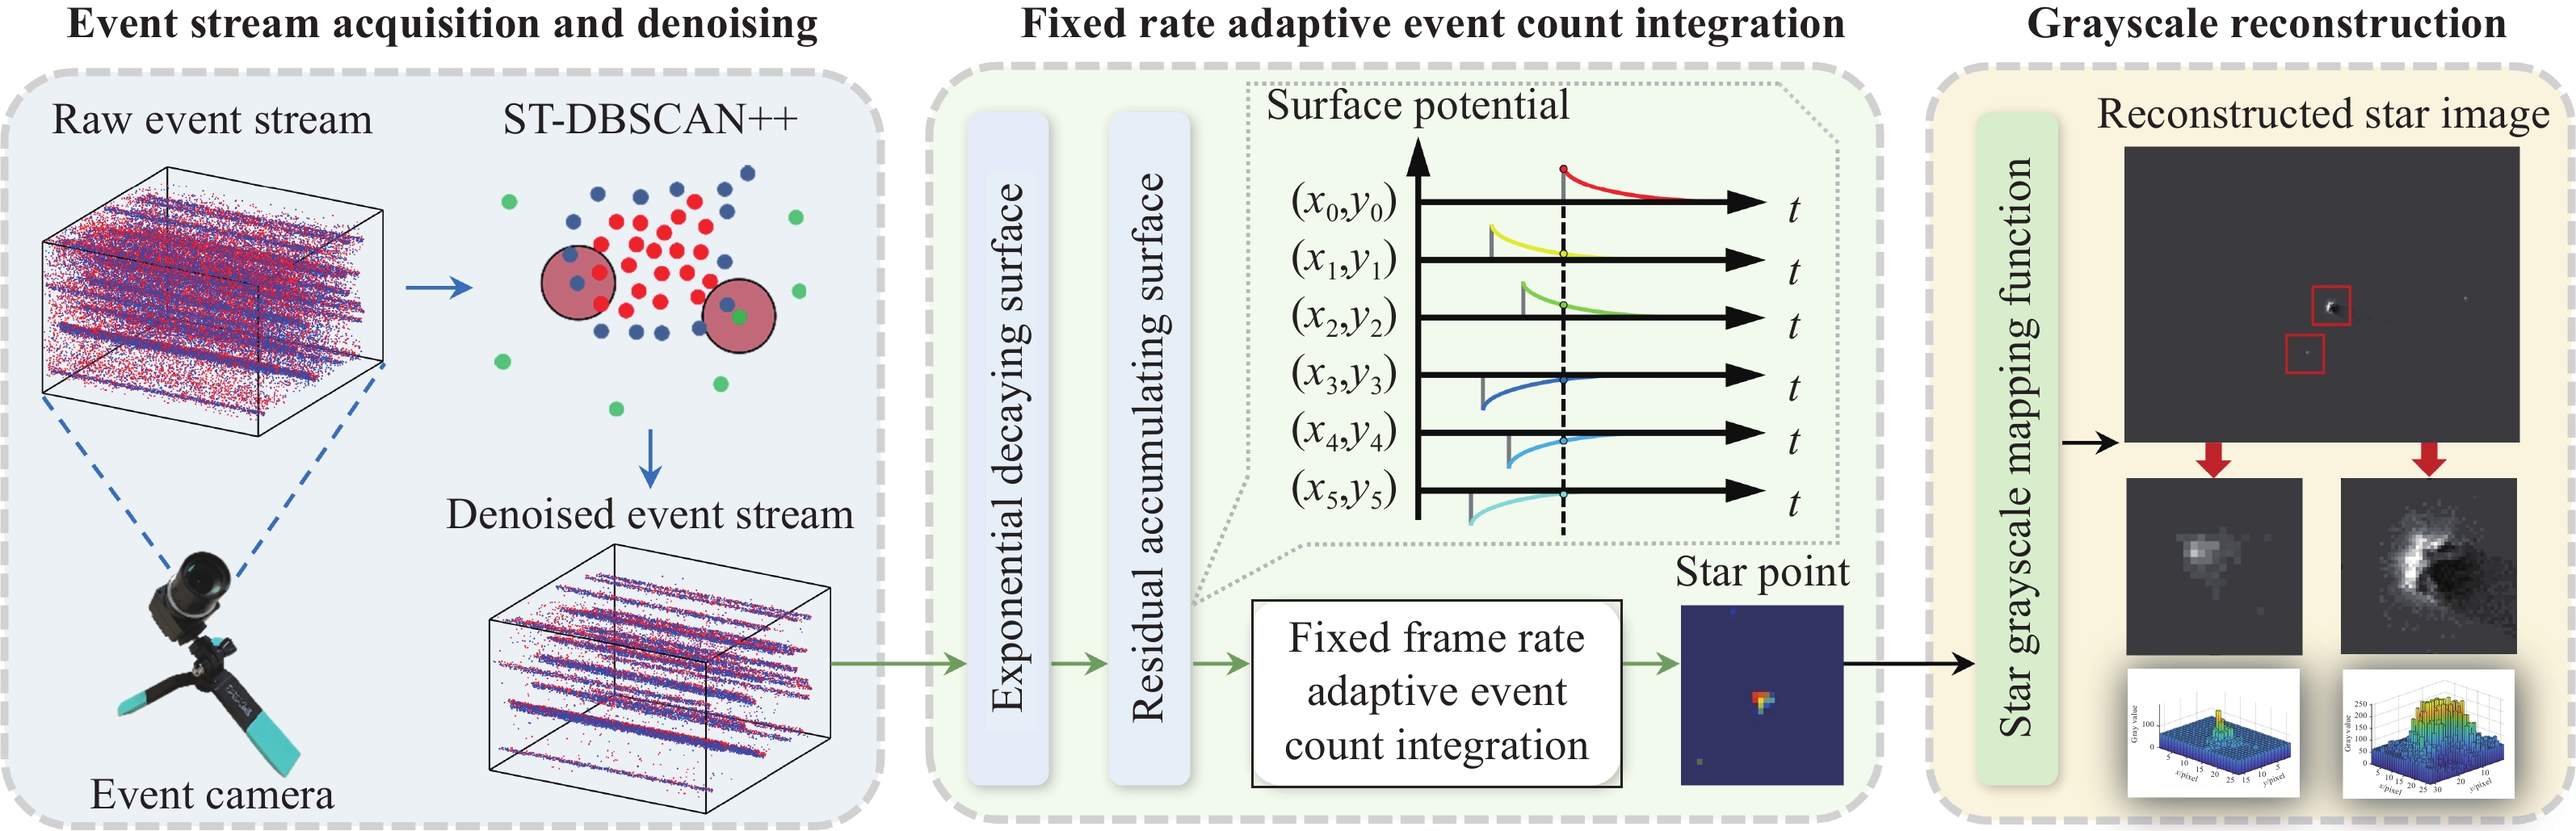
图 1 基于残差累积表面的事件星敏感器自适应积分算法框架图
Figure 1. Algorithm framework of adaptive integration algorithm for event-based star sensor based on residual accumulating surface
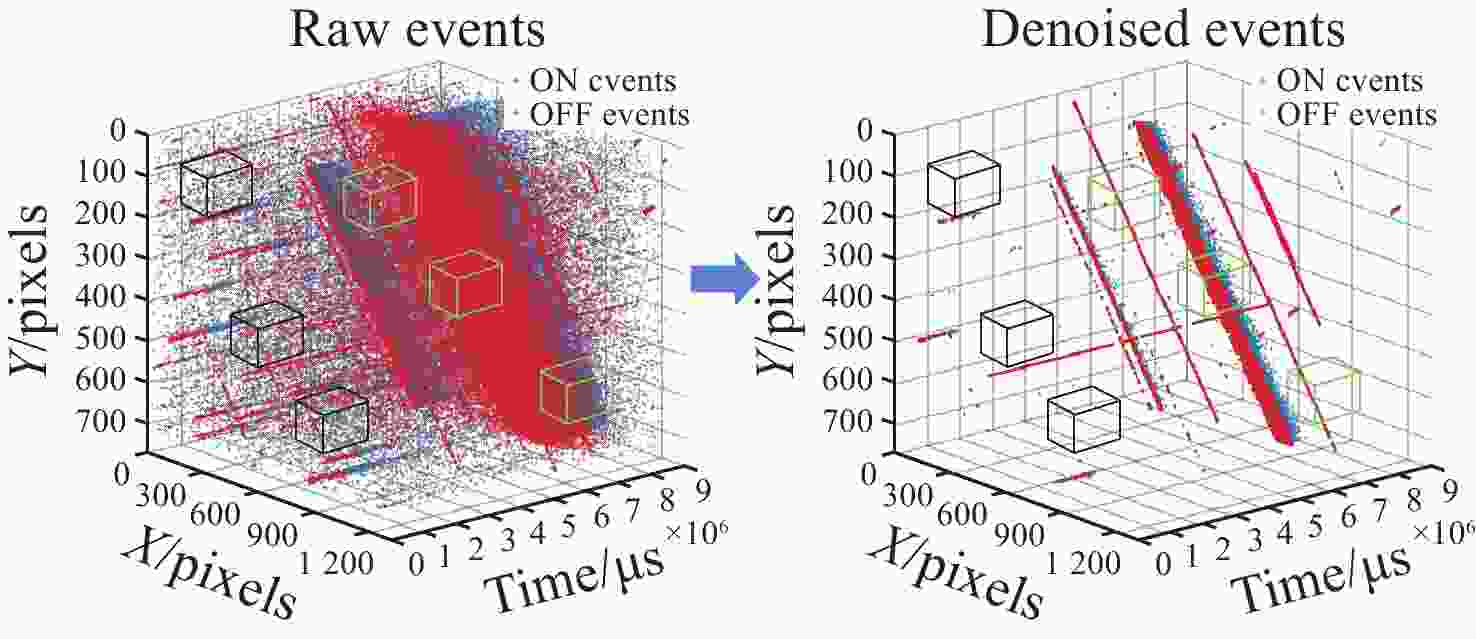
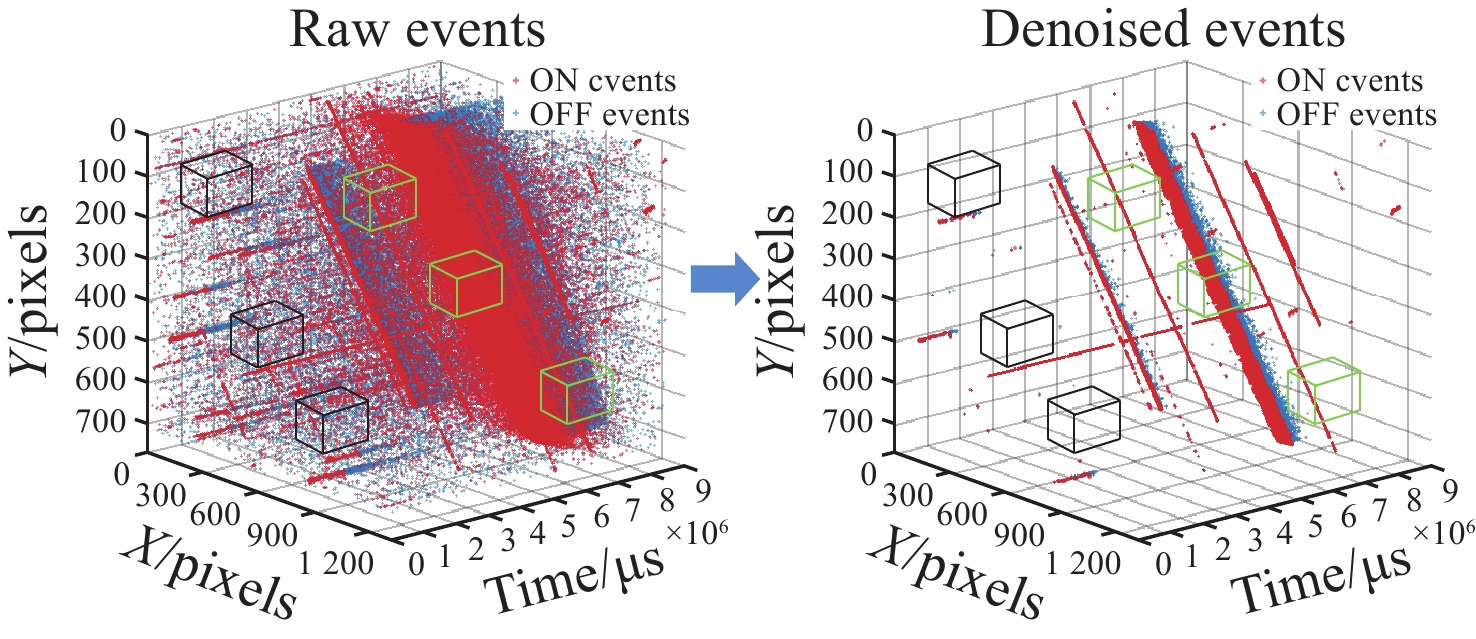
图 4 去噪效果评价区域选择机制。黑色长方体框选的区域为背景噪声区域,绿色长方体框选的区域为星点目标区域
Figure 4. Denoising effect evaluation region selection mechanism. The area selected by the black cuboid is the background noise area, and the area selected by the green cuboid is the star target area
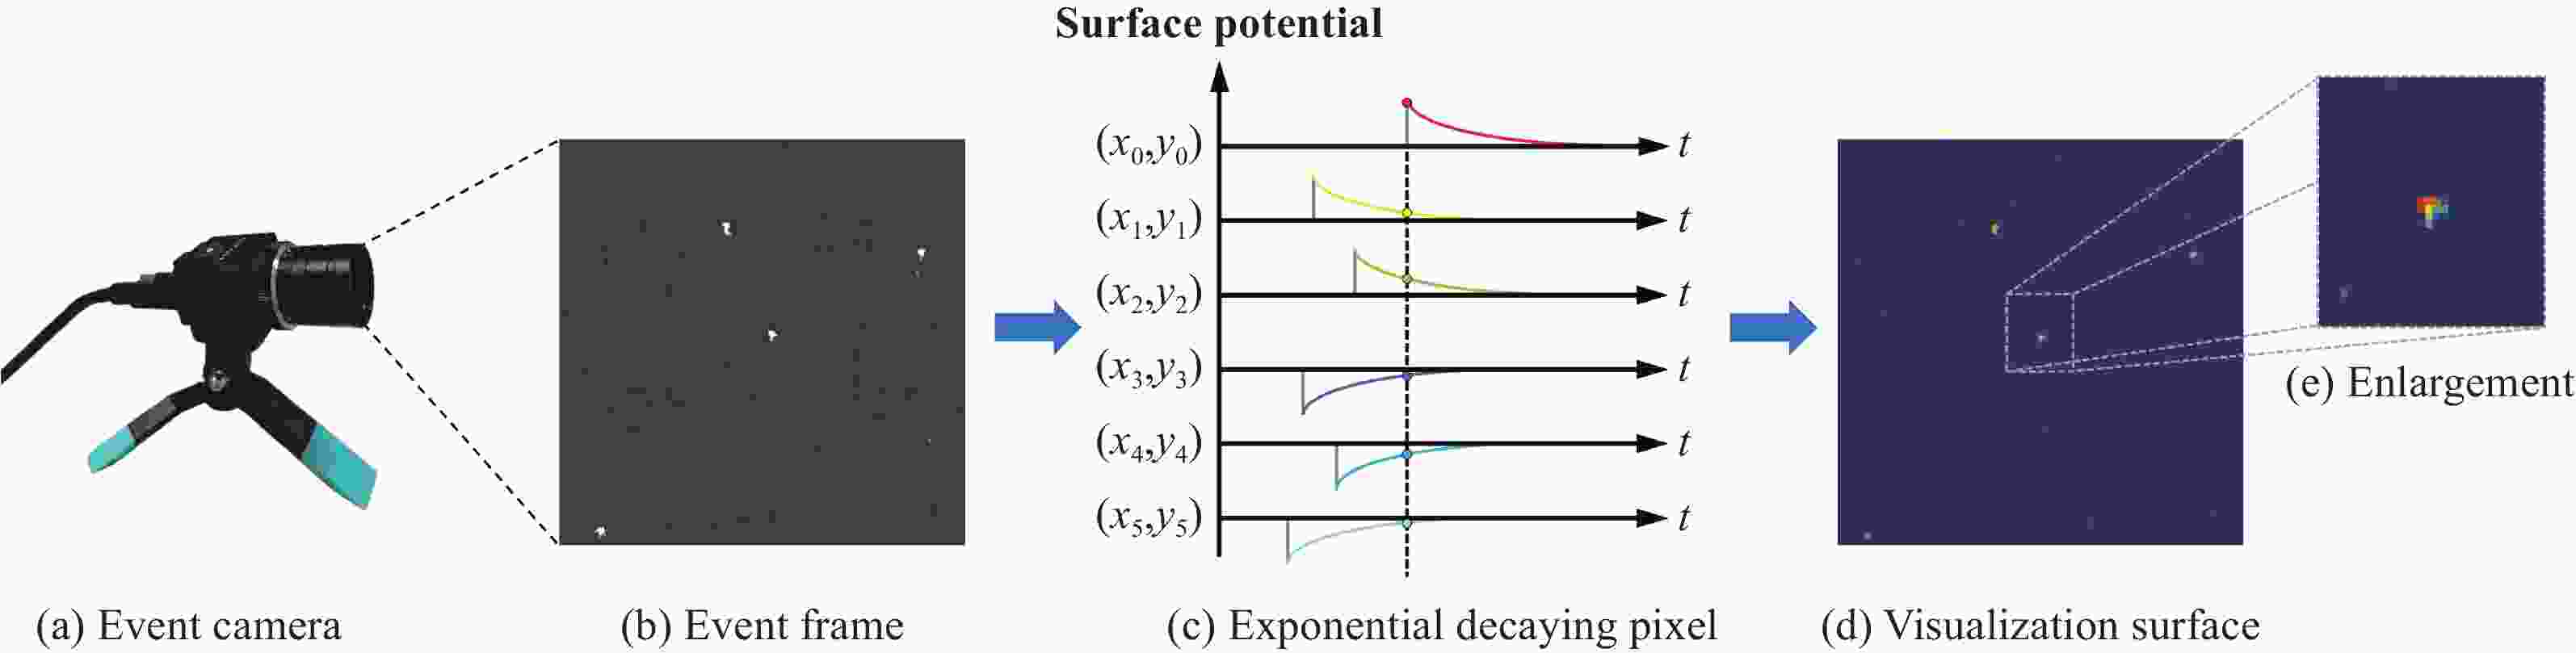
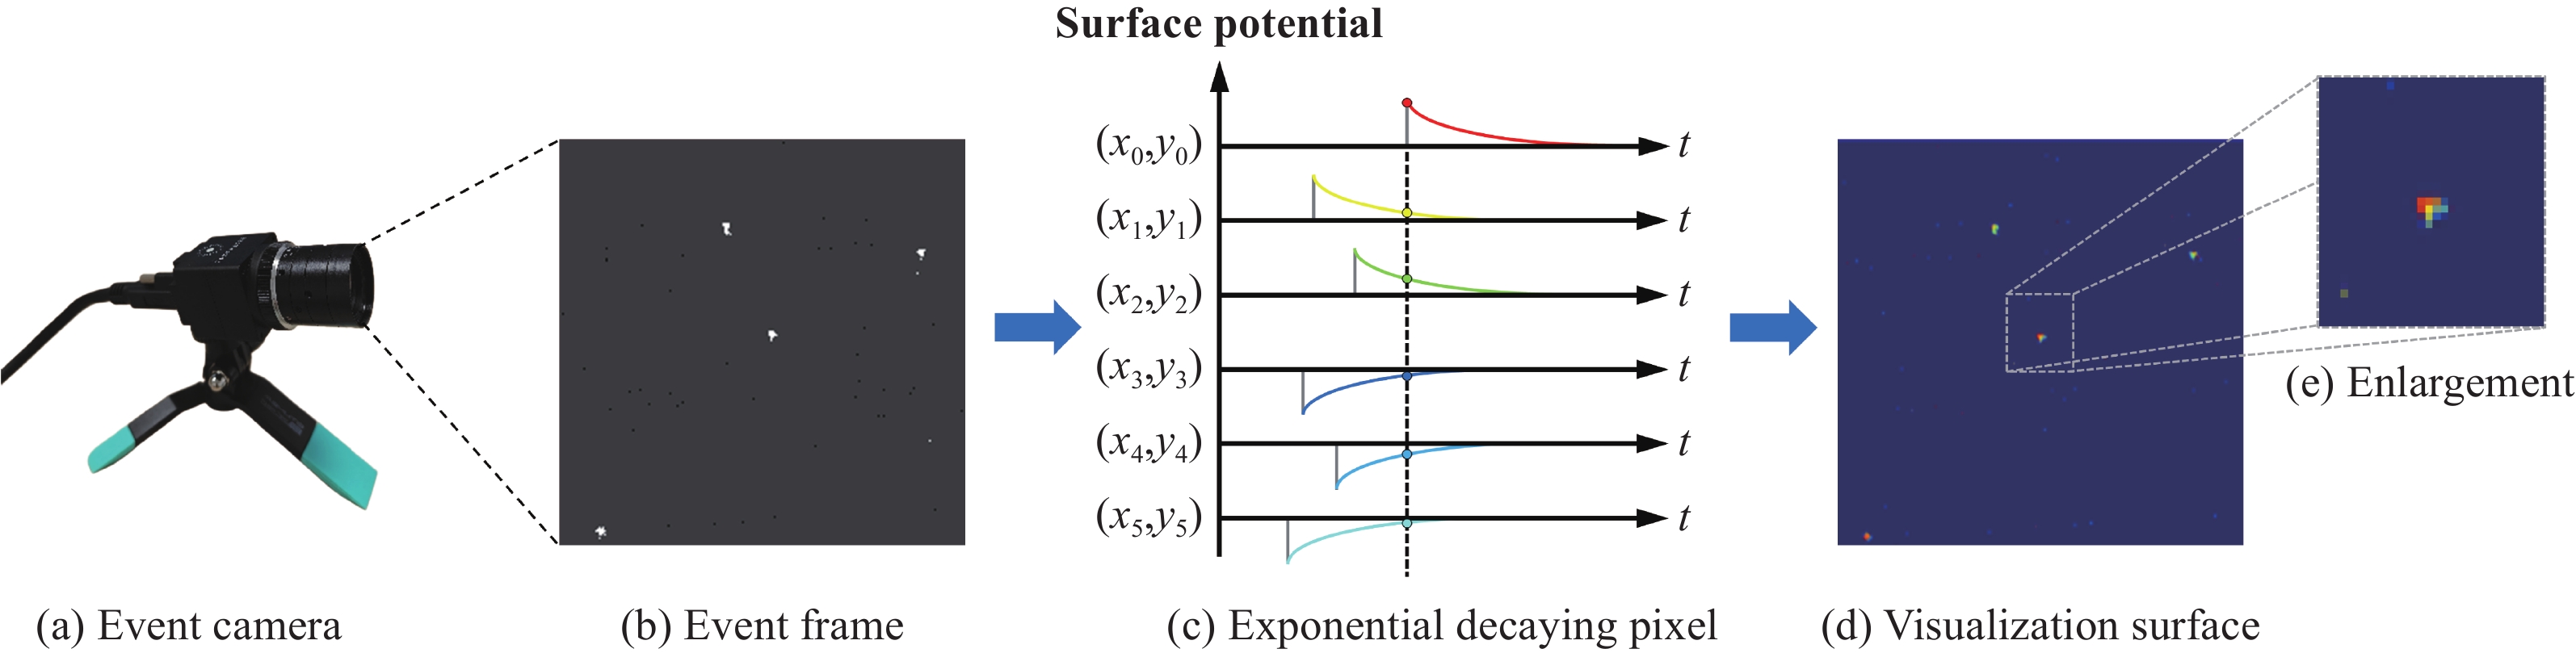
图 5 指数衰减表面生成过程示意图
Figure 5. Schematic diagram of the exponential decaying surface generation process
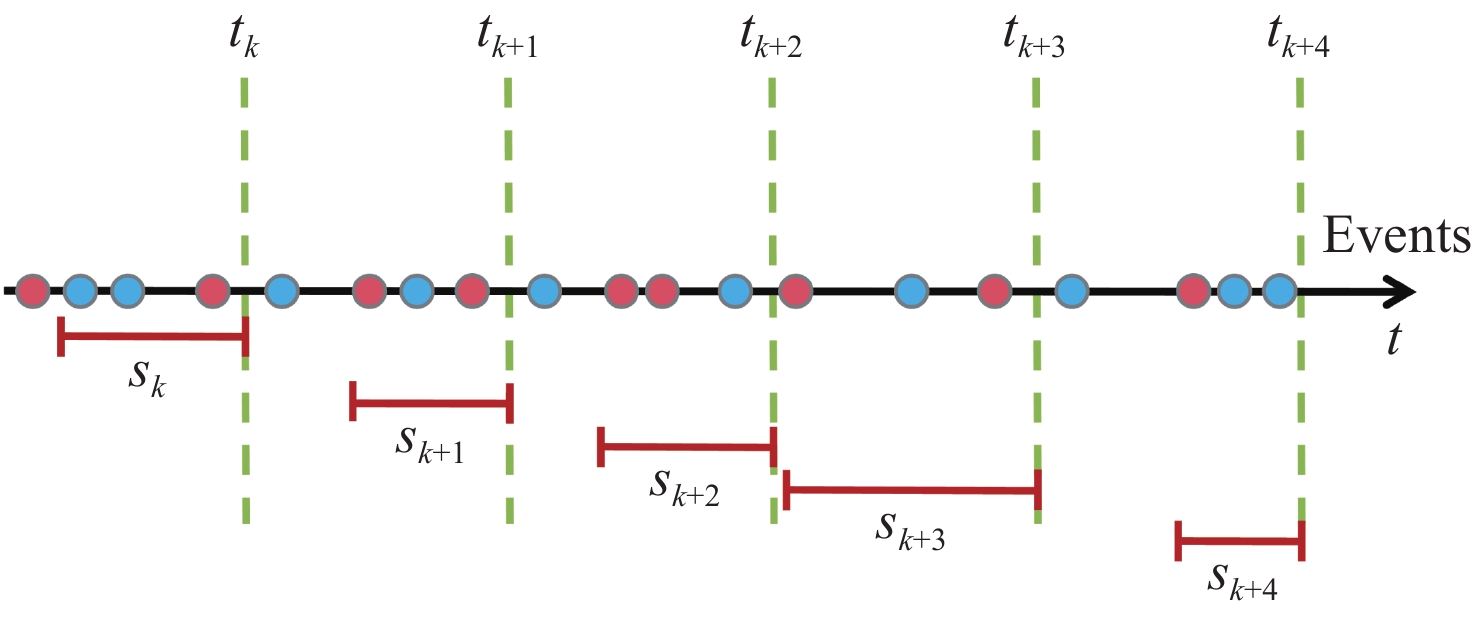
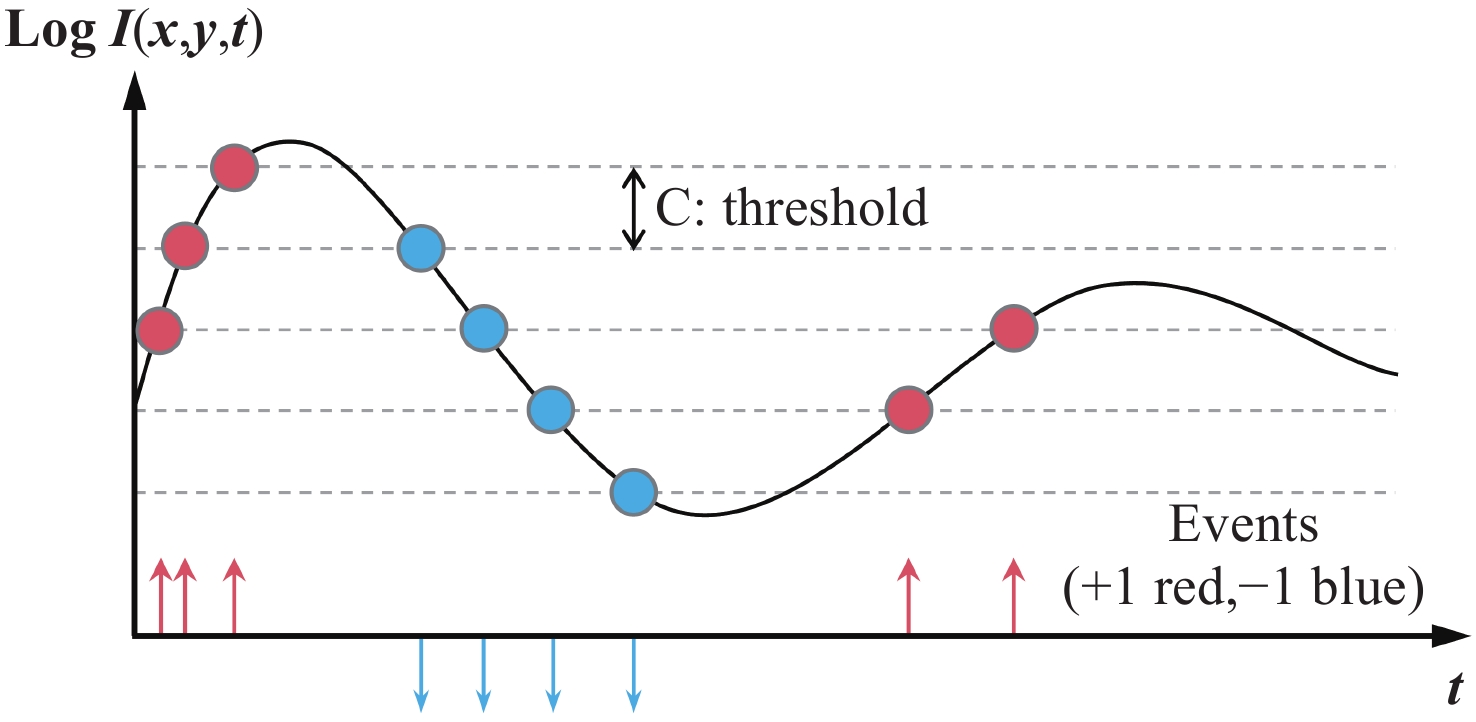
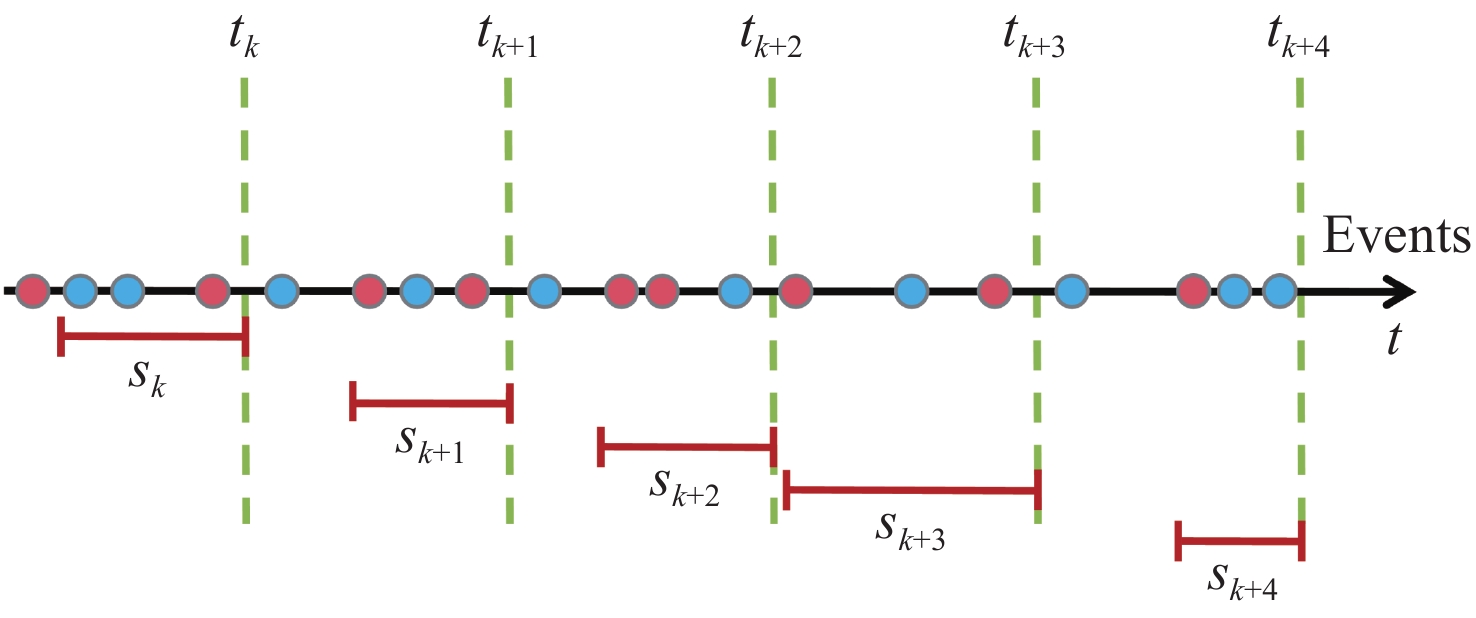
图 6 自适应事件时空切片选择机制。图中的红点为极性为+1的事件,蓝点为极性为-1的事件,绿色虚线为标准帧的采样时间戳。红色线段界定了被选取的事件时空区域。每个切片的事件数量会自动适应运动速率,本示例中
$ {S}_{k} $ 至$ {S}_{k+4} $ 的各切片均包含3个事件。Figure 6. Adaptive event spatiotemporal slice selection mechanism. In the diagram, red dots represent events with a polarity of +1, blue dots represent events with a polarity of −1, and the green dashed line represents the sampling timestamp of the standard frame. The red line segment defines the selected event spatiotemporal region. The number of events in each slice automatically adapts to the motion rate; in this example, each slice from
$ {S}_{k} $ to$ {S}_{k+4} $ contains 3 events.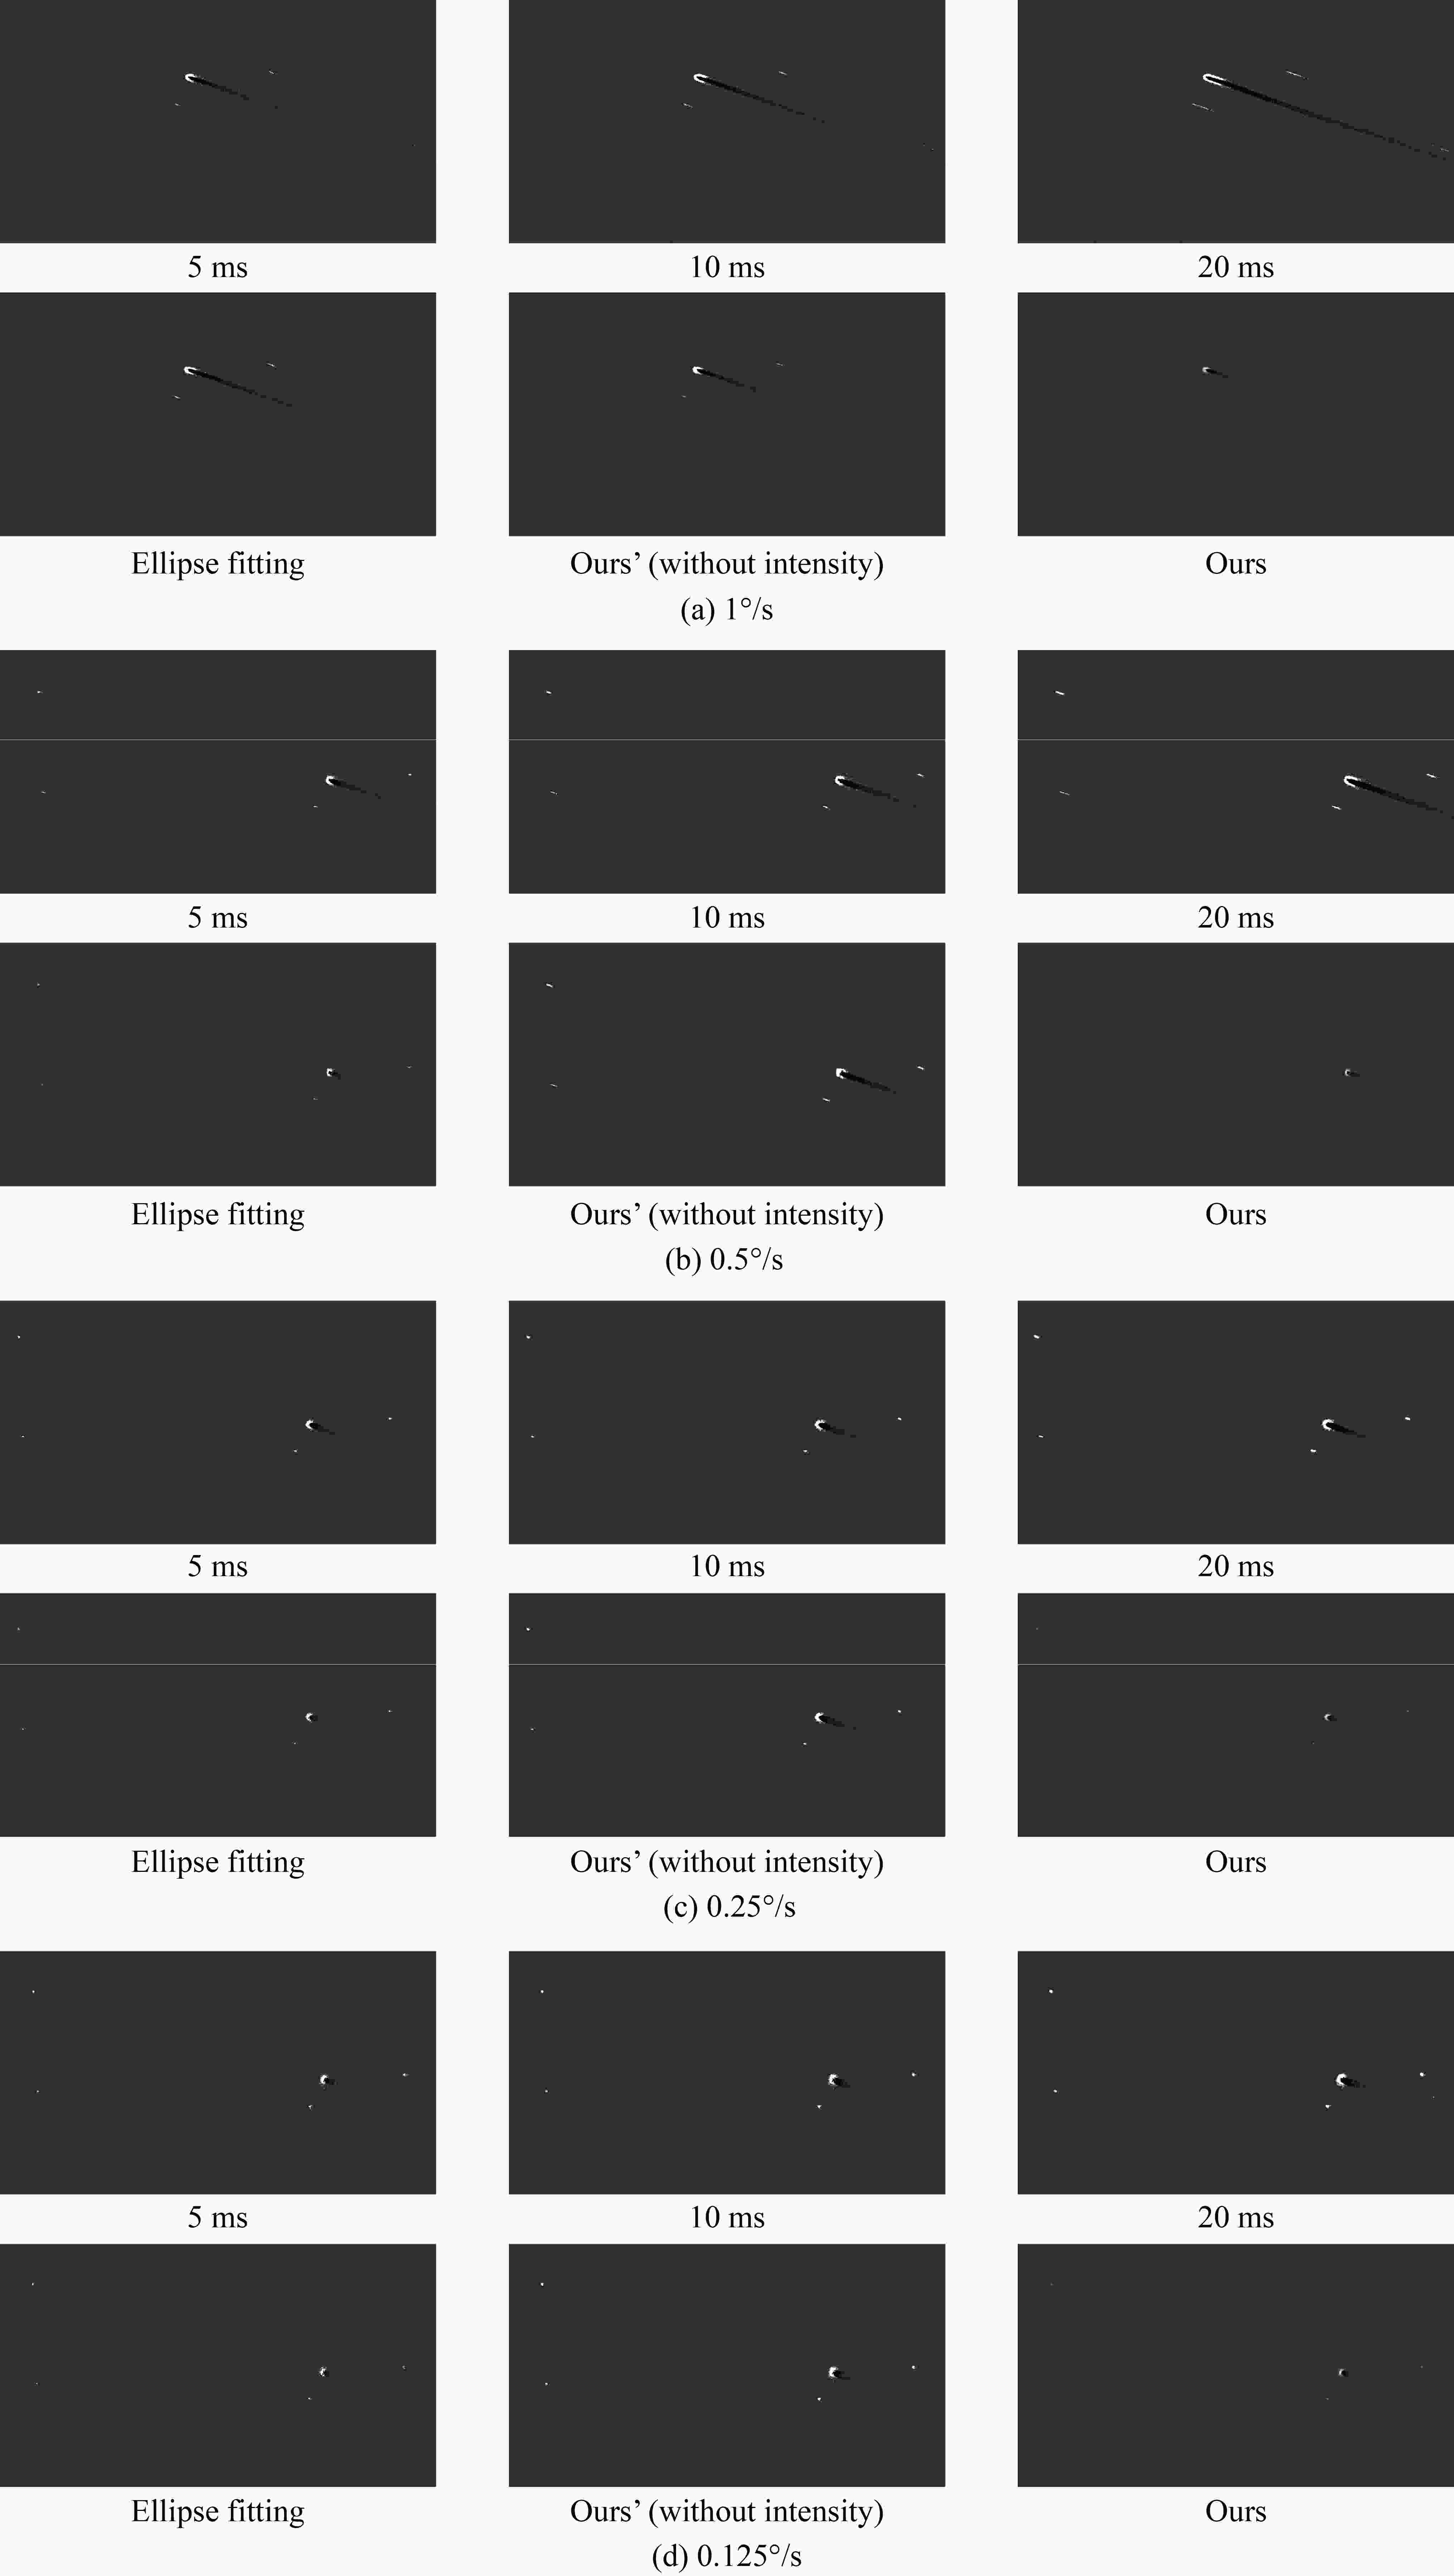
图 8 不同积分方法在不同角速度下的星点成像效果对比
Figure 8. Comparison of star imaging effects of different integration methods at different angular velocities
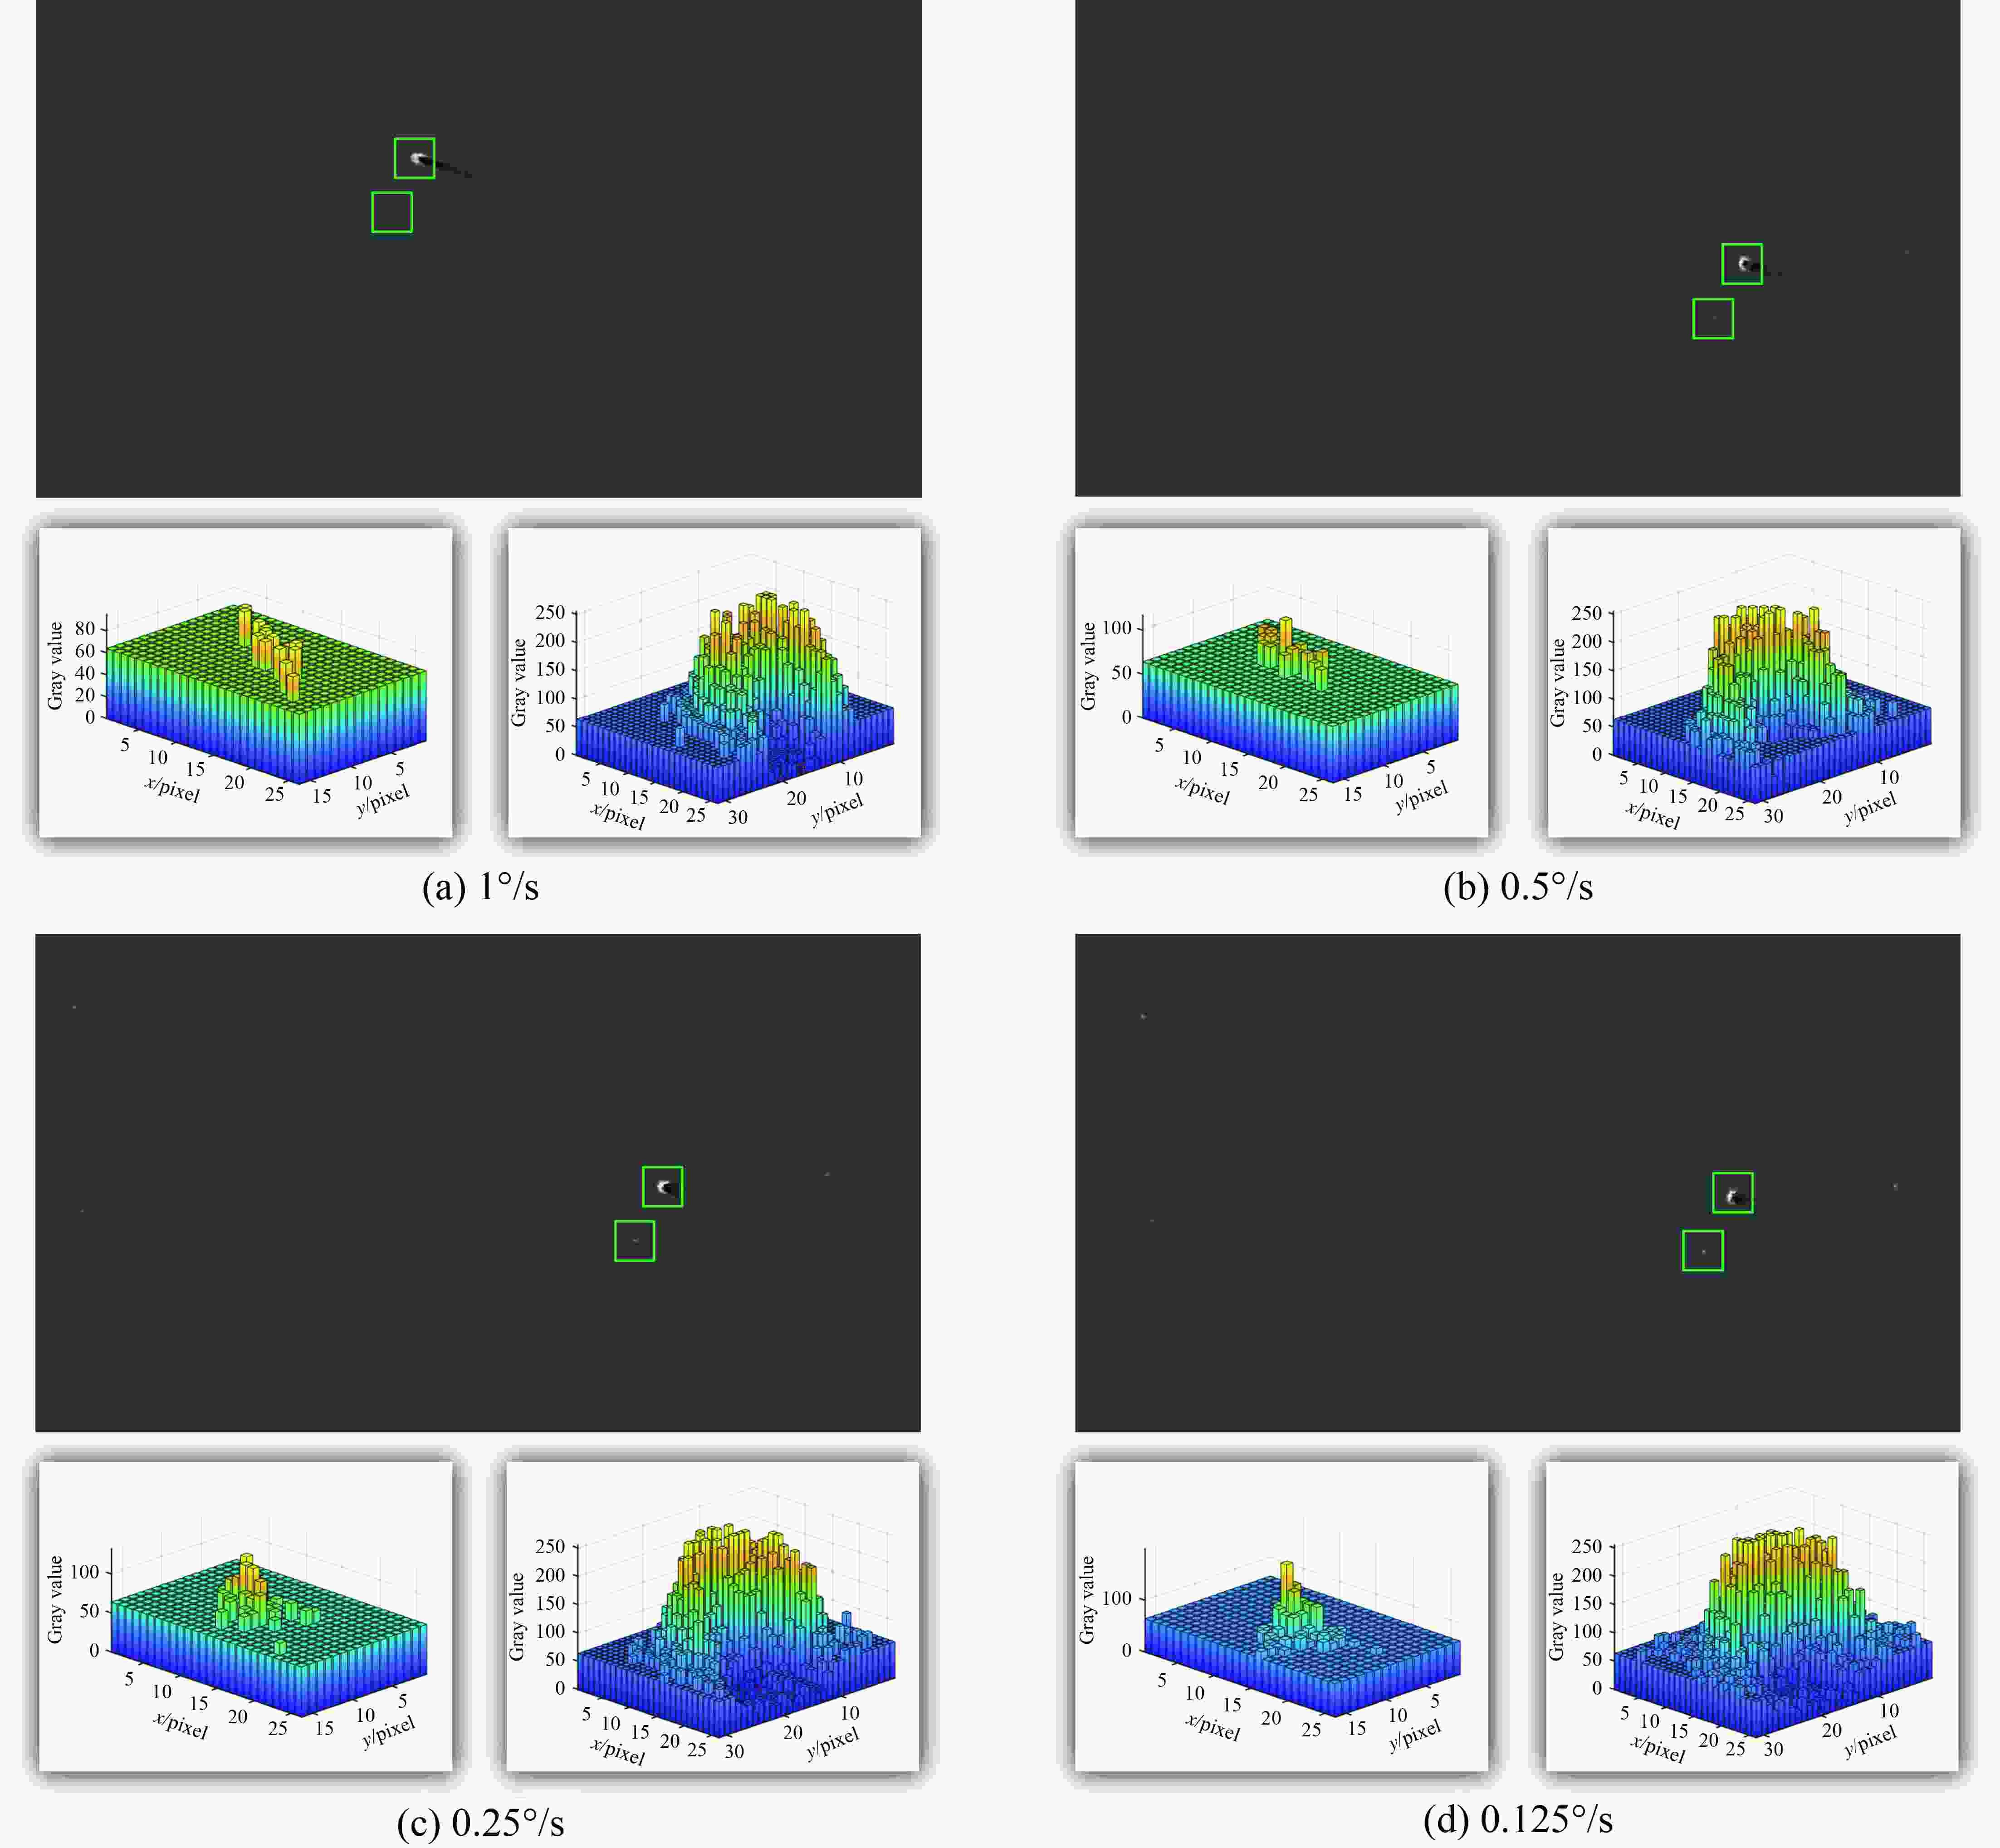
图 9 本文算法在不同角速度下生成的星点伪灰度响应分布。(a) 1°/s; (b) 0.5°/s; (c) 0.25°/s; (d) 0.125°/s。每组中左侧为低事件响应的暗弱星点,右侧为高事件响应的较亮星点
Figure 9. Pseudo-grayscale response distributions of star spots generated by the proposed algorithm at different angular velocities. (a) 1°/s; (b) 0.5°/s; (c) 0.25°/s; (d) 0.125°/s. In each group, the left panel shows a dim star with a low event response, whereas the right panel shows a relatively bright star with a high event response.
表 1 观测星场的天体测量属性
Table 1. Astrometric Properties of the Observed Star Fields
Field ID
Field CenterCentral Source HIP ID Magnitude RA(deg) Dec(deg) 0 95.987926 − 52.695660 Canopus 30438 −0.74 1 114.825500 5.224993 Procyon 37279 0.34 2 191.930378 − 59.688764 Mimosa 62434 1.25 3 125.628542 − 59.509483 Avior 41037 1.86 4 182.103152 − 24.728782 Alchiba 59199 4.02 5 144.302803 6.835782 10 Leo 47205 5.00  下载: 导出CSV
表 2 算法去噪效果评估结果
Table 2. Algorithm denoising performance evaluation results
$ \omega $ (°/s) Raw Events Method Reduction (%) DER↑ SRR↑ DEA↑ Time (s) ↓ 1.0 ~550K 1-Stage STF 37.65 1 0.7215 1.7215 3.23 Cascaded STF 39.49 1 0.7391 1.7391 6.79 Proposed 27.61 1 0.8216 1.8216 1.74 0.5 ~780K 1-Stage STF 34.43 1 0.8366 1.8366 4.22 Cascaded STF 41.26 1 0.8796 1.8796 11.45 Proposed 25.04 1 0.9357 1.9357 2.12 0.25 ~1.15M 1-Stage STF 34.19 1 0.6959 1.6959 6.00 Cascaded STF 41.12 1 0.7724 1.7724 13.68 Proposed 25.44 1 0.8439 1.8439 2.72 0.125 ~1.71M 1-Stage STF 36.70 1 0.5596 1.5596 9.21 Cascaded STF 44.92 1 0.6327 1.6327 22.95 Proposed 25.29 1 0.6967 1.6967 3.82
下载: 导出CSV
表 3 1°/s场景下各模块消融实验结果
Table 3. Ablation results of each module at 1°/s
Method Denoising Adaptive integration RAS reconstruction X error (px) ↓ Y error (px) ↓ Angular distance (arcsec) ↓ Fixed 5 ms √ × × 3.28 4.19 4.14 Fixed 10 ms √ × × 9.98 6.60 4.81 Fixed 20 ms √ × × 22.85 6.60 7.89 Ellipse Fitting √ √ (time window) × 5.09 2.67 3.80 Ours' (w/o RAS) √ √ (event count) × 3.28 1.77 3.45 Ours (full) √ √ (event count) √ 1.92 1.21 3.35
下载: 导出CSV
表 4 不同角速度下的事件回溯与有效测量时刻统计
Table 4. Event look-back and effective measurement time at different angular velocities
$ \omega $ (°/s) Frames Look-back event count $ \mathrm{N} $$ \text{N} $,
median $ [{P}_{25},{P}_{75}] $Look-back temporal span $ \mathit{\Delta }T $,
median $ [{P}_{25},{P}_{75}] $ (ms)Effective measurement time lag $ \text{δt} $$ \delta t $,
median $ [{P}_{25},{P}_{75}] $ (ms)1.0 617 742 [536, 1098 ]1.34 [1.12, 1.44] 0.287 [0.239, 0.336] 0.5 731 1018 [681,1472 ]2.56 [2.13, 2.75] 0.548 [0.454, 0.639] 0.25 990 1387 [918,2056 ]4.83 [4.06, 5.13] 1.012 [0.846, 1.179] 0.125 1458 1716 [1124 ,2648 ]8.94 [7.58, 9.43] 1.873 [1.574, 2.176]
下载: 导出CSV
表 5 去噪阶段关键参数敏感性分析
Table 5. Sensitivity analysis of key parameters in the denoising stage
Metric Angular velocity
$ {\varepsilon }_{1} $ (pixels)
$ {\varepsilon }_{2} $ (ms)2 3 4* 5 6 4 6 8* 10 12 SRR 1.0 °/s 0.784 0.805 0.822 0.833 0.841 0.792 0.808 0.822 0.832 0.840 0.5 °/s 0.909 0.924 0.936 0.943 0.948 0.917 0.927 0.936 0.942 0.946 0.25 °/s 0.811 0.829 0.844 0.855 0.862 0.819 0.833 0.844 0.853 0.859 0.125 °/s 0.652 0.676 0.697 0.714 0.728 0.664 0.681 0.697 0.709 0.718 Avg. time(s) — 2.52 2.58 2.62 2.69 2.76 2.58 2.60 2.62 2.65 2.67
下载: 导出CSV
表 6 积分阶段关键参数敏感性分析
Table 6. Sensitivity analysis of key parameters in the integration stage
Metric Angular velocity
$ \tau $ (ms)
$ {\gamma }_{\max } $5 8 10* 15 20 1.2 1.3 1.5* 1.8 2.0 Average centroid error
(pixels)1.0 °/s 1.90 1.67 1.56 1.70 1.86 1.76 1.64 1.56 1.61 1.66 0.5 °/s 2.83 2.58 2.46 2.60 2.79 2.69 2.55 2.46 2.51 2.56 0.25 °/s 2.60 2.41 2.31 2.38 2.53 2.50 2.38 2.31 2.34 2.38 0.125 °/s 1.48 1.35 1.28 1.31 1.39 1.40 1.32 1.28 1.29 1.31 Note: Average centroid error denotes the arithmetic mean of the median centroid errors in the X and Y directions.
*indicates the default parameter used in this paper.
下载: 导出CSV
表 7 不同角速度条件下各模块平均耗时统计
Table 7. Statistics on average time consumed by each module under different angular velocities
$ \omega $ (°/s) Raw Events Stage 1 / s Stage 2 / s RAS / s Adaptive / s Centroid / s Total time /s 1 ~550K 0.42 1.32 0.11 1.62 0.14 3.61 0.5 ~780K 0.68 1.44 0.12 1.82 0.16 4.22 0.25 ~1.15M 0.95 1.77 0.13 1.75 0.17 4.77 0.125 ~1.71M 1.42 2.40 0.14 1.90 0.19 6.05
下载: 导出CSV
-
[1] SANG P, LIU W B, CAO Y, et al. Research on precise attitude measurement technology for satellite extension booms based on the star tracker[J]. Sensors, 2024, 24(20): 6671. doi: 10.3390/s24206671 [2] 支帅, 丁国鹏, 韩世豪, 等. 基于单相机的空间目标相对位姿测量系统[J]. 中国光学(中英文), 2025, 18(5): 1111-1123.ZHI SH, DING G P, HAN SH H, et al. Monocular camera-based relative position and orientation estimation system for space targets[J]. Chinese Optics, 2025, 18(5): 1111-1123. (in Chinese). [3] MA L H, DAI D K, NI Y M. How to improve the attitude accuracy of the star sensor under dynamic conditions: a review[J]. Acta Astronautica, 2025, 233: 42-54. doi: 10.1016/j.actaastro.2025.03.043 [4] DU J Y, WEI X G, LI J, et al. Star spot extraction for multi-FOV star sensors under extremely high dynamic conditions[J]. IEEE Sensors Journal, 2024, 24(21): 35167-35180. doi: 10.1109/JSEN.2024.3459001 [5] YI J H, MA Y B, ZHU Z F, et al. A blurred star image restoration method based on gyroscope data and enhanced sparse model[J]. Measurement Science and Technology, 2023, 34(11): 115105. doi: 10.1088/1361-6501/ace730 [6] 阮宇翔, 董磊. 干涉星敏感器测角精度影响因素的研究[J]. 中国光学(中英文), 2023, 16(6): 1433-1441.RUAN Y X, DONG L. Influencing factors of angle measurement accuracy of an interferometer star tracker[J]. Chinese Optics, 2023, 16(6): 1433-1441. (in Chinese). [7] 王燕清, 杜伟峰, 吴永康, 等. 星敏感器在轨精度分析[J]. 光学学报, 2025, 45(12): 1228002. doi: 10.3788/AOS241726WANG Y Q, DU W F, WU Y K, et al. Analysis of star sensor in-orbit accuracy[J]. Acta Optica Sinica, 2025, 45(12): 1228002. (in Chinese). doi: 10.3788/AOS241726 [8] HAN J X, NIU ZH D, HE J. Restoration of non-uniform motion-blurred star images based on dynamic strip attention[J]. Journal of Imaging, 2026, 12(3): 103. doi: 10.3390/jimaging12030103 [9] ZHANG B F, ZHAO SH Y, LIU Z Y. A review of image restoration methods based on the Richardson-Lucy algorithm[J]. Digital Signal Processing, 2026, 169: 105768. doi: 10.1016/j.dsp.2025.105768 [10] LIU D, CHEN X Y, LIU X. An improved Richardson-Lucy algorithm for star image deblurring[C]. 2019 IEEE International Instrumentation and Measurement Technology Conference (I2MTC), IEEE, 2019: 1-5. [11] GEHRIG D, SCARAMUZZA D. Low-latency automotive vision with event cameras[J]. Nature, 2024, 629(8014): 1034-1040. doi: 10.1038/s41586-024-07409-w [12] LI ZH X, YAN H D, DING G P, et al. Dual-modality event-frame fusion for blind star image motion deblurring via sparse residual learning[J]. Optics and Lasers in Engineering, 2025, 195: 109368. doi: 10.1016/j.optlaseng.2025.109368 [13] BAGCHI S, CHIN T J. Event-based star tracking via multiresolution progressive Hough transforms[C]. Proceedings of the IEEE Winter Conference on Applications of Computer Vision, IEEE, 2020: 2132-2141. [14] COHEN G, AFSHAR S, MORREALE B, et al. Event-based sensing for space situational awareness[J]. The Journal of the Astronautical Sciences, 2019, 66(2): 125-141. doi: 10.1007/s40295-018-00140-5 [15] 曾思康, 赵汝进, 马跃博, 等. 基于事件的高动态星敏感器星点提取方法[J]. 光子学报, 2022, 51(9): 0912003. doi: 10.3788/gzxb20225109.0912003ZENG S K, ZHAO R J, MA Y B, et al. An event-based method for extracting star points from high dynamic star sensors[J]. Acta Photonica Sinica, 2022, 51(9): 0912003. (in Chinese). doi: 10.3788/gzxb20225109.0912003 [16] 朱立华, 张强, 高建东, 等. 事件星敏感器自适应积分时间曲面算法[J]. 中国惯性技术学报, 2023, 31(10): 1016-1022. doi: 10.13695/j.cnki.12-1222/o3.2023.10.009ZHU L H, ZHANG Q, GAO J D, et al. Adaptive integration time surface algorithm for event-based star tracker[J]. Journal of Chinese Inertial Technology, 2023, 31(10): 1016-1022. (in Chinese). doi: 10.13695/j.cnki.12-1222/o3.2023.10.009 [17] RALPH N O, MARCIREAU A, AFSHAR S, et al. Astrometric calibration and source characterisation of the latest generation neuromorphic event-based cameras for space imaging[J]. Astrodynamics, 2023, 7(4): 415-443. doi: 10.1007/s42064-023-0168-2 [18] LIU H N, SUN T, TIAN Y, et al. Measurement techniques for highly dynamic and weak space targets using event cameras[J]. Sensors, 2025, 25(14): 4366. doi: 10.3390/s25144366 [19] BAGCHI S, ANASTASIOU P, TETLOW M, et al. Event-based star tracking under spacecraft jitter: the e-STURT dataset[J]. IEEE Transactions on Aerospace and Electronic Systems, 2026, 62: 4629-4645. doi: 10.1109/TAES.2026.3653351 [20] REED A W, HASHEMI C, MELAMED D, et al. EBS-EKF: accurate and high frequency event-based star tracking[C]. Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition, IEEE, 2025: 6510-6519. [21] CAPOGROSSO L, BONAZZI P, MAGNO M. Event-based vision in space: applications, trends, and future directions[J]. arXiv preprint arXiv: 2606.01280, 2026. (查阅网上资料, 请核对文献类型及格式是否正确). [22] COCKRAM M, MARTINEZ REY N. Event-based detectors for laser guide star tip-tilt sensing[J]. Optical Engineering, 2025, 64(4): 043102. doi: 10.1117/1.oe.64.4.043102 [23] CHIN T J, BAGCHI S, ERIKSSON A, et al. Star tracking using an event camera[C]. Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition Workshops, IEEE, 2019: 1646-1655. [24] VITORIA P, GEORGOULIS S, TULYAKOV S, et al. Event-based image deblurring with dynamic motion awareness[C]. Proceedings of the 17th European Conference on Computer Vision, Springer, 2022: 95-112. [25] CHEN K, YU L. Motion deblur by learning residual from events[J]. IEEE Transactions on Multimedia, 2024, 26: 6632-6647. doi: 10.1109/TMM.2024.3355630 [26] 闫浩东, 支帅, 陈旭睿, 等. 基于模型和样条的星敏感器在轨自标定方法[J]. 光学学报, 2024, 44(12): 1212004. doi: 10.3788/AOS240580YAN H D, ZHI SH, CHEN X R, et al. On-orbit self-calibration method for star sensors based on models and splines[J]. Acta Optica Sinica, 2024, 44(12): 1212004. (in Chinese). doi: 10.3788/AOS240580 [27] HE X, ZHANG L, HE J W, et al. A voting-based star identification algorithm using a partitioned star catalog[J]. Applied Sciences, 2025, 15(1): 397. doi: 10.3390/app15010397 [28] 顾佳林, 吕恒毅, 李卓贤, 等. 融合特征增强与轻量级注意力的事件去模糊[J/OL]. 中国光学(中英文), (2026-04-22). https://doi.org/10.37188/CO.2026-0011. (查阅网上资料,请补充引用日期).GU J L, LV H Y, LI ZH X, et al. Event deblurring via feature enhancement and lightweight attention[J/OL]. Chinese Optics. (2026-04-22). https://doi.org/10.37188/CO.2026-0011. (in Chinese). [29] LI J N, XU J T, GAO J D. Clustering-based temporal deep neural network denoising method for event-based sensors[J]. Optoelectronics Letters, 2025, 21(7): 441-448. doi: 10.1007/s11801-025-4091-z [30] JIANG H Y, WANG X SH, TANG W, et al. Event stream denoising method based on spatio-temporal density and time sequence analysis[J]. Sensors, 2024, 24(20): 6527. doi: 10.3390/s24206527 [31] 吕媛媛. 基于事件相机的物体振动特性测量技术研究[D]. 西安: 中国科学院大学(中国科学院西安光学精密机械研究所), 2024.LV Y Y. Research on measurement technology of object vibration characteristics based on event camera[D]. Xi’an: University of Chinese Academy of Sciences (Xi’an Institute of Optics & Precision Mechanics, Chinese Academy of Sciences), 2024. (in Chinese). [32] LANG D, HOGG D W, MIERLE K, et al. Astrometry. net: blind astrometric calibration of arbitrary astronomical images[J]. The Astronomical Journal, 2010, 139(5): 1782-1800. doi: 10.1088/0004-6256/139/5/1782 [33] HØG E, FABRICIUS C, MAKAROV V V, et al. The Tycho-2 Catalogue of the 2.5 million brightest stars[J]. Astronomy & Astrophysics, 2000, 355(2): L27-L30. [34] LINDEGREN L, HERNÁNDEZ J, BOMBRUN A, et al. Gaia data release 2-the astrometric solution[J]. Astronomy & Astrophysics, 2018, 616: A2. -

 下载:


计量
- 文章访问数: 15
- HTML全文浏览量: 7
- PDF下载量: 0
- 被引次数: 0
