

Error correction method for binocular stereo vision in temperature-humidity coupling field based on fixed target array
-
摘要:
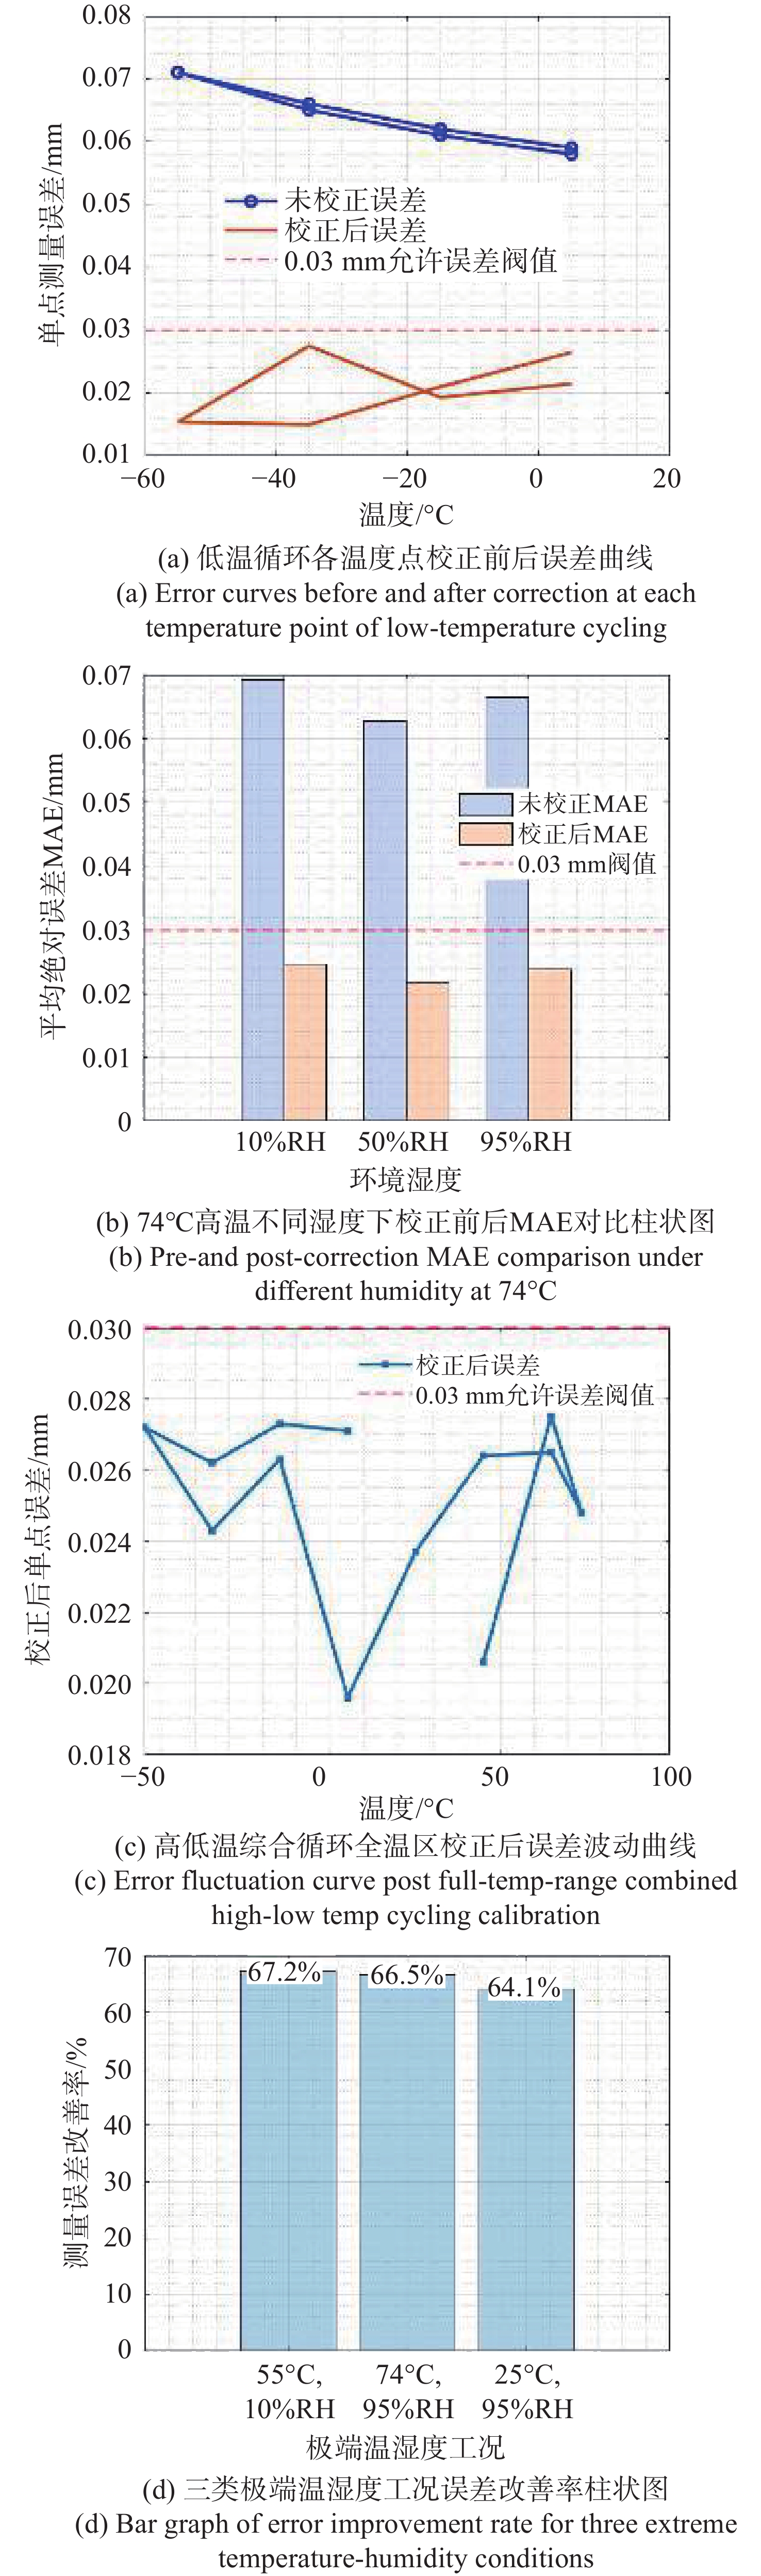
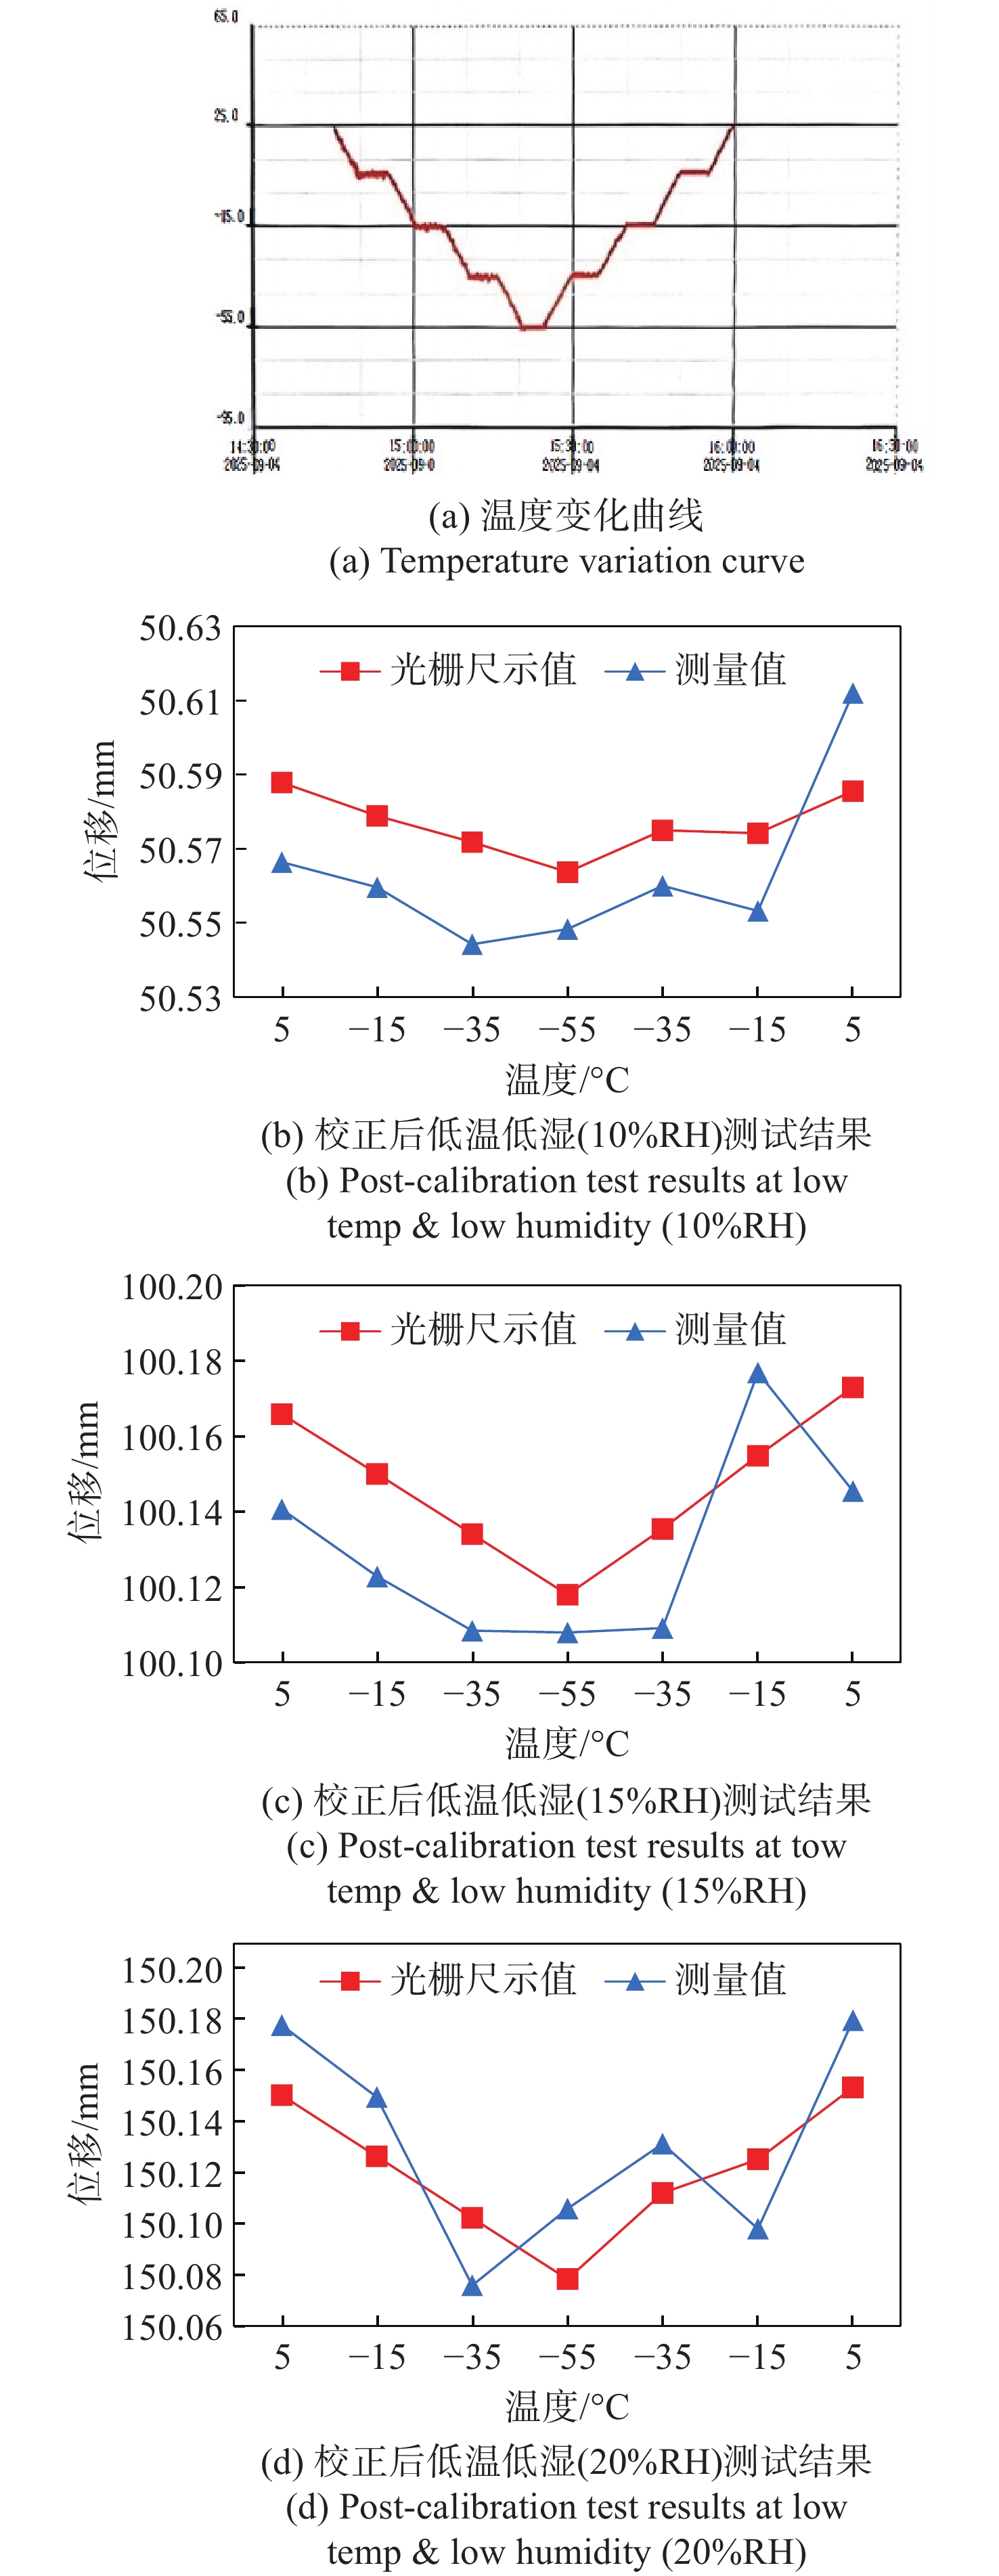
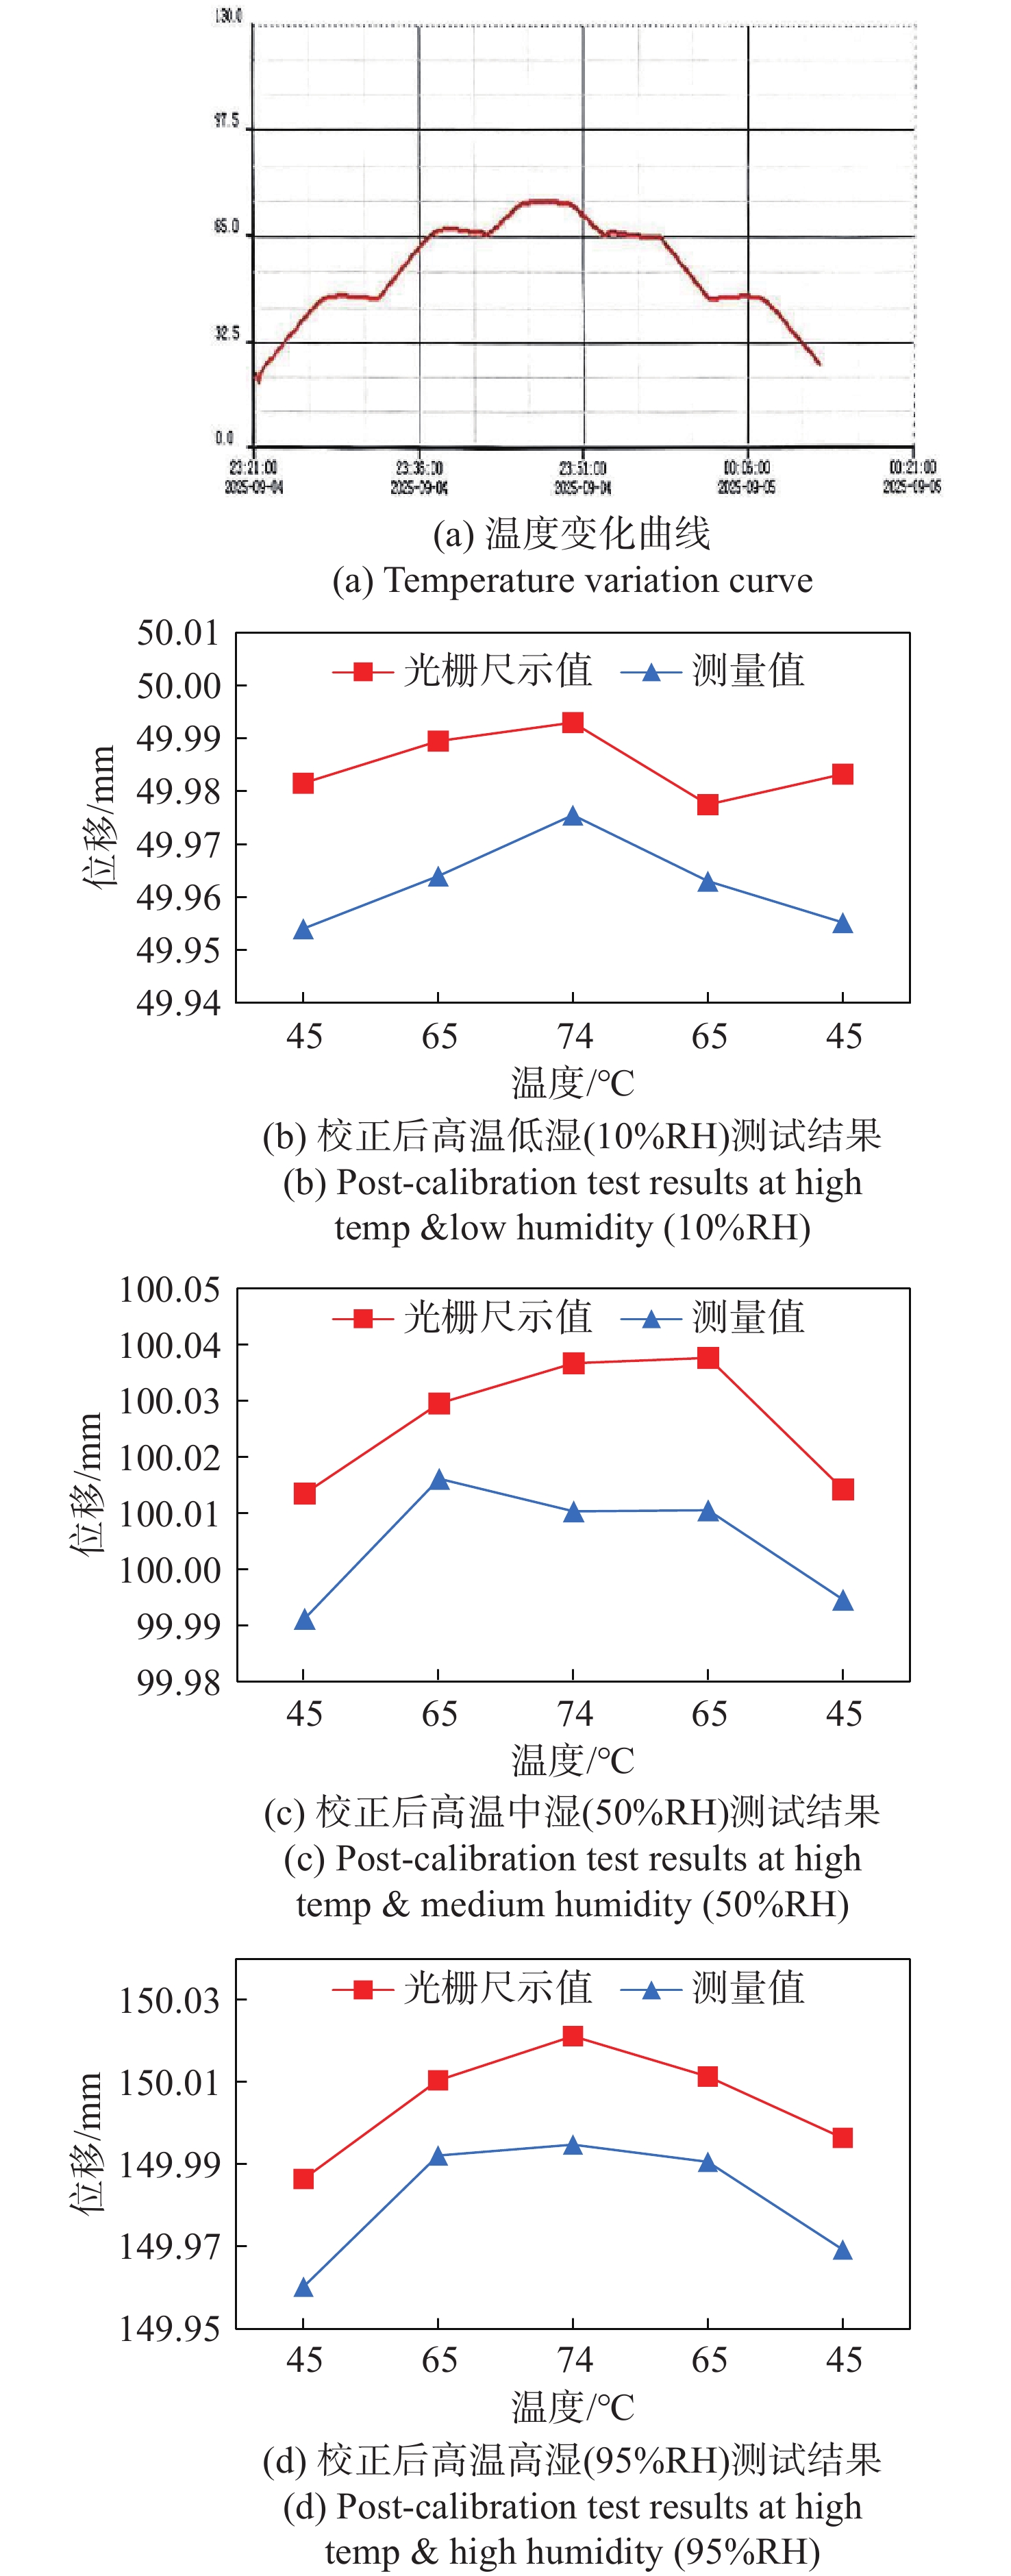
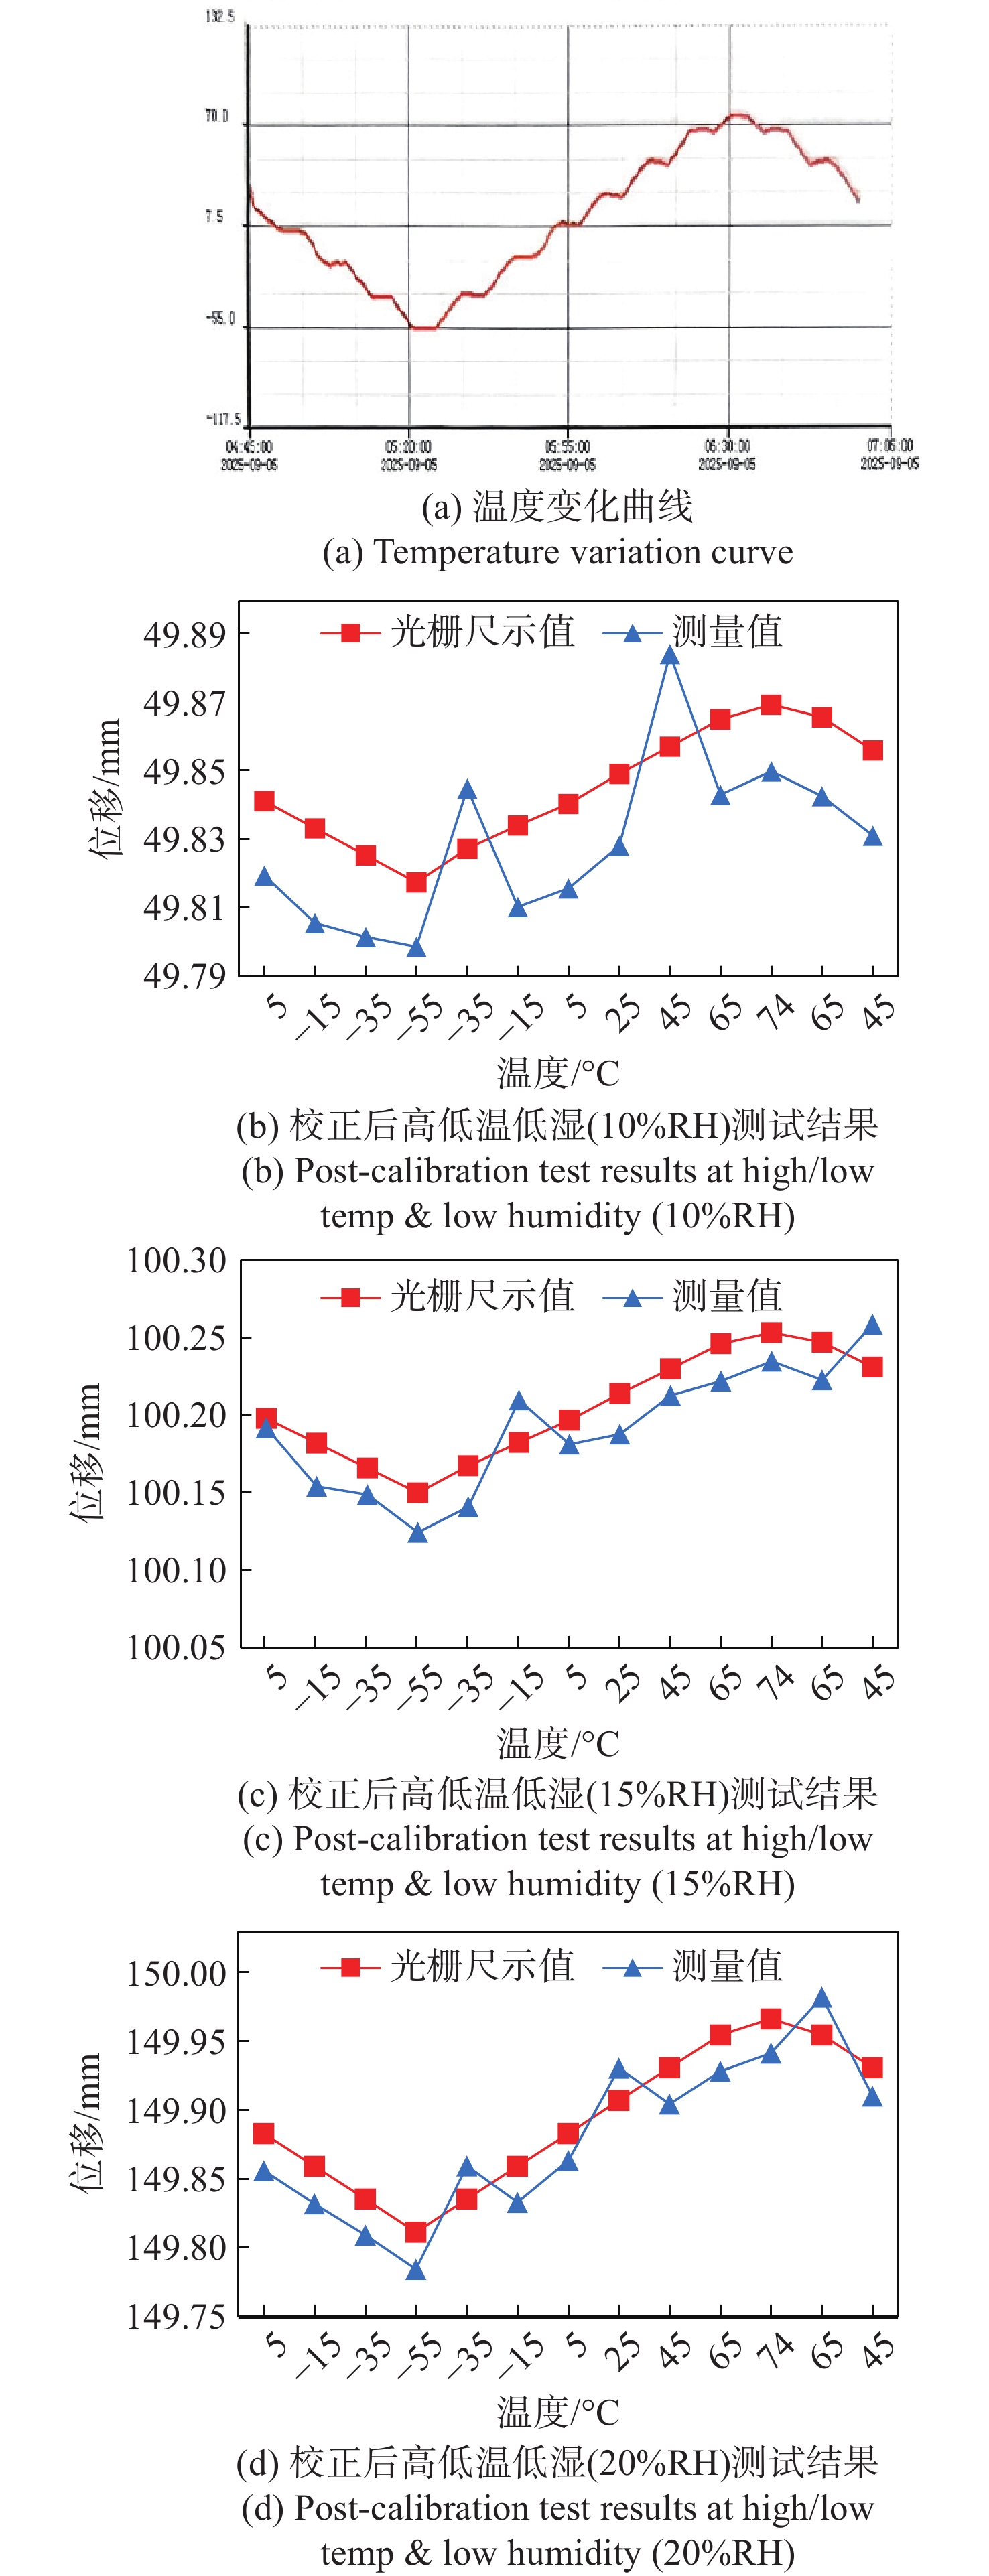
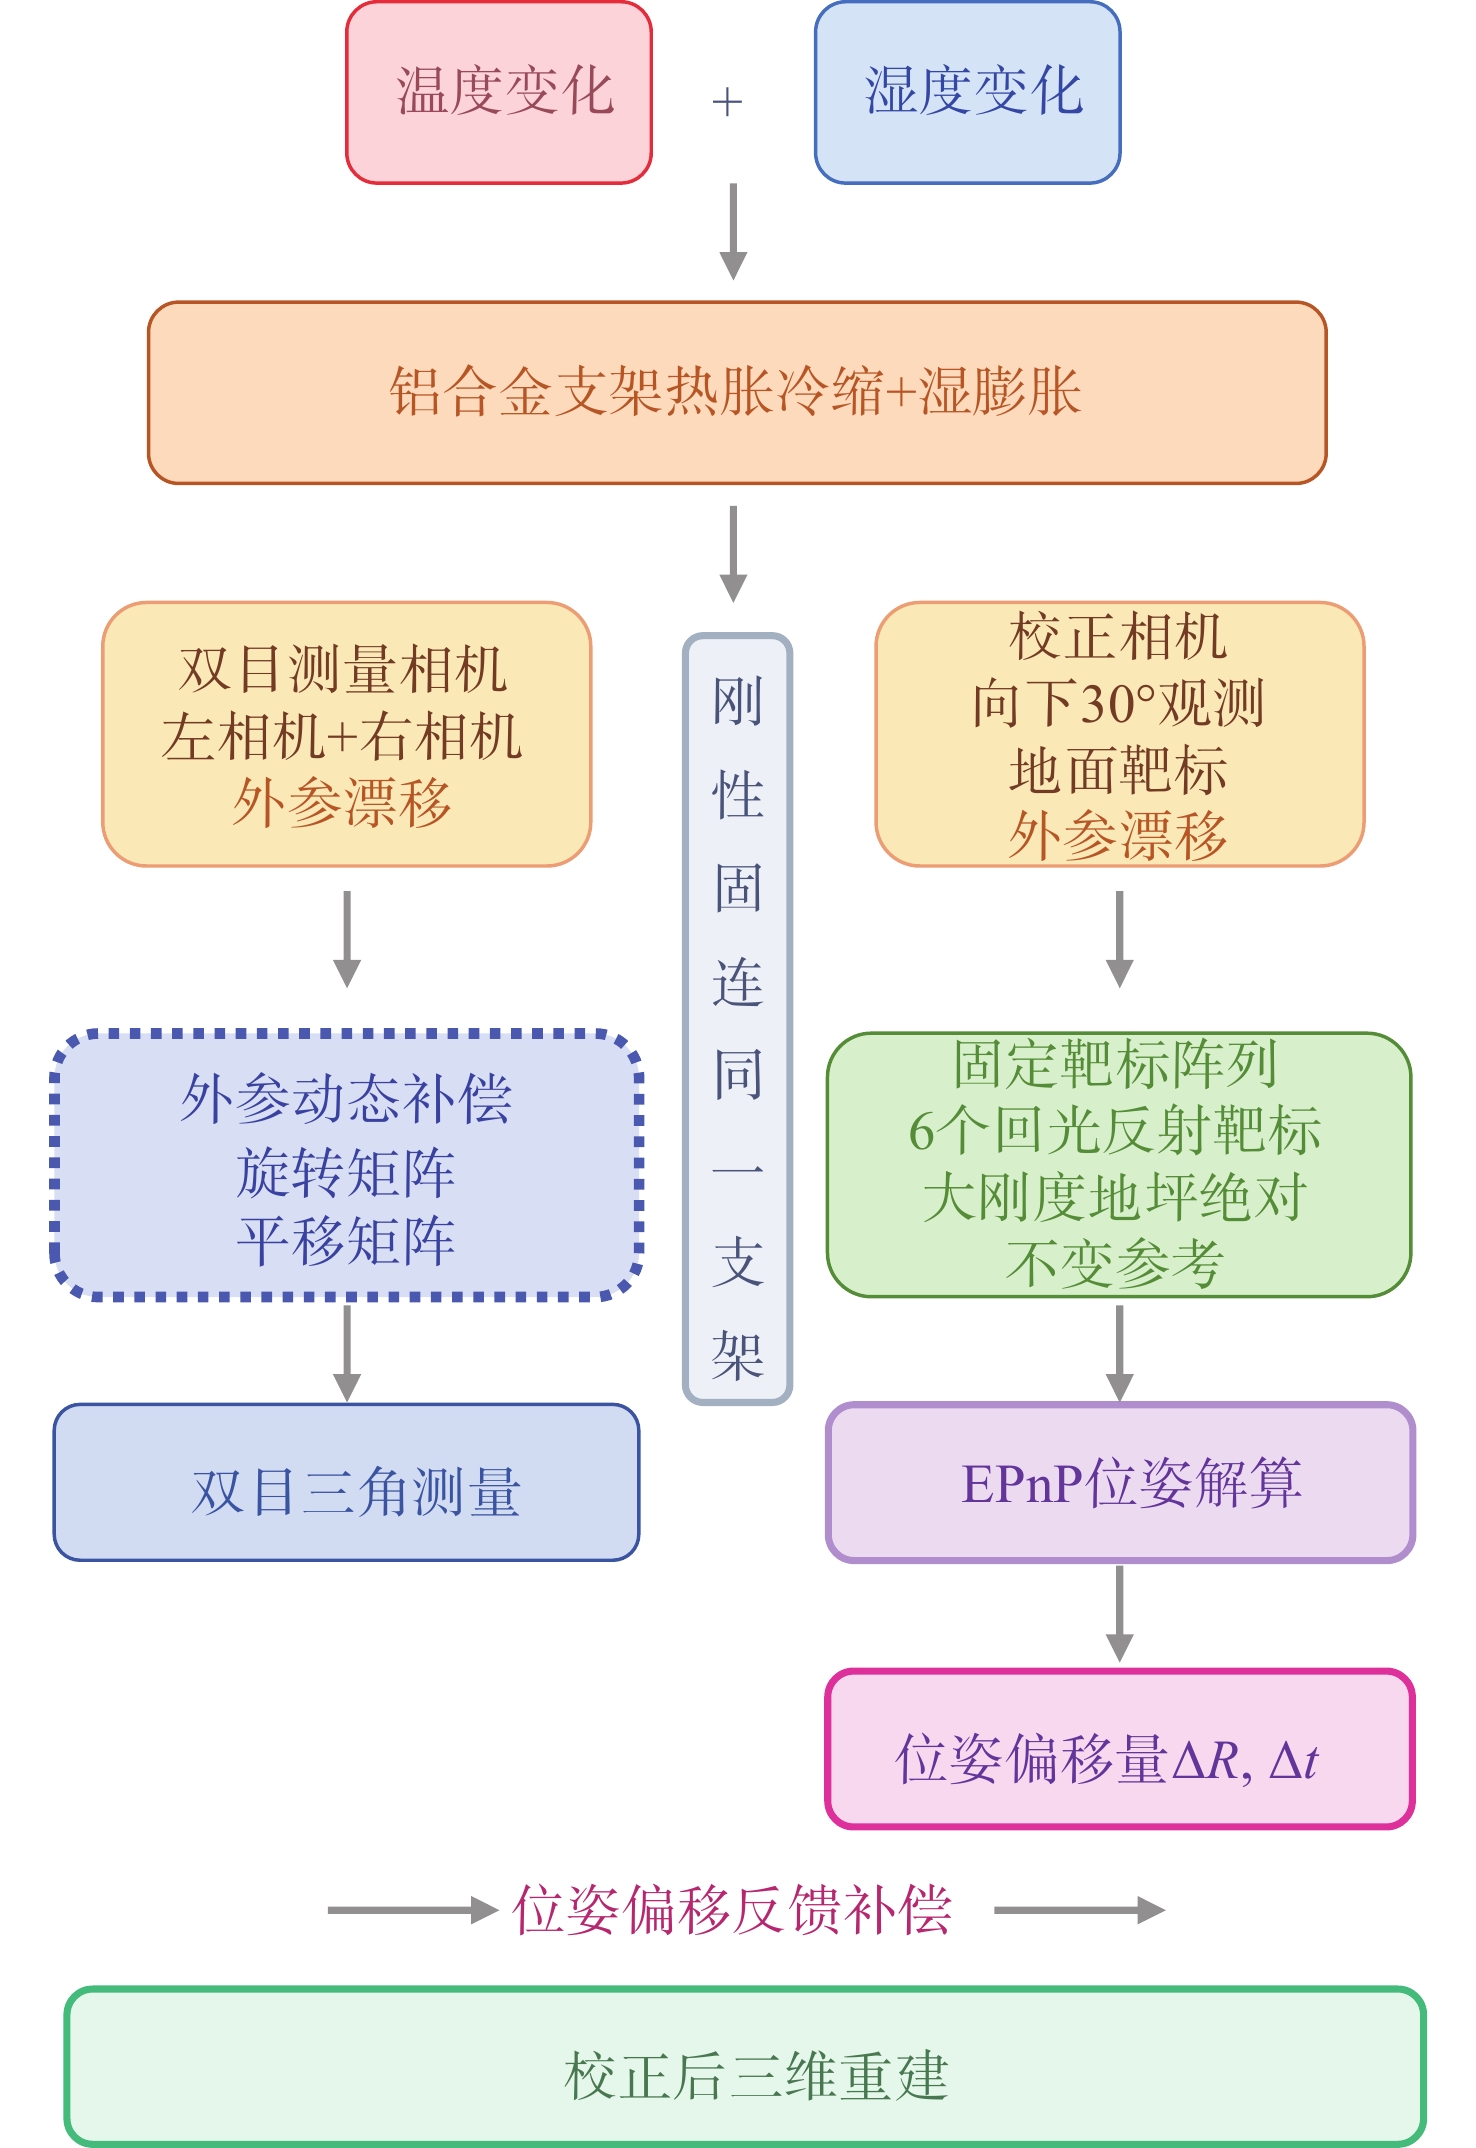
针对飞机结构气候强度试验宽温湿度耦合环境中,铝合金相机支架温变形变引发双目相机外参漂移以及现有自校正方法难以适配高低温-高低湿耦合工况的问题,本文提出基于高刚度地坪固定靶标阵列的双目视觉实时误差校正方法,构建含热膨胀、湿膨胀及交叉耦合项的位姿偏移数学模型,推导温湿度扰动下外参误差传递方程,增设辅助校正相机观测固定靶标,采用EPnP算法解算支架位姿偏移,动态补偿双目系统外参。并通过仿真及9组环境箱实验开展验证,以光栅尺(精度为0.5 μm)作为参考基准,实验覆盖低温、高温、全温域综合循环工况。仿真和实验结果表明:未校正时系统平均测量误差0.065 mm,全部工况超出0.03 mm允许误差,经本方法校正后,各工况平均绝对误差MAE为
0.0209 ~0.0253 mm,单点最大误差0.0278 mm,测量标准差大幅降低及数据重复性明显提升,仿真误差改善率64.2%~65.8%。本文方案仅增加一台校正相机与固定靶标阵列,无需额外温度、位移传感器,硬件成本低、易于集成,能够满足航空大型结构气候强度试验的高精度三维变形测量需求。Abstract:To address the issue of extrinsic parameter drift in binocular cameras induced by thermo-hygroscopic deformation of metallic camera supports within wide-range temperature–humidity coupled environments during aircraft structural climatic strength testing, as well as the inability of existing self-calibration methods to adapt to coupled high/low-temperature and high/low-humidity conditions, this paper proposes a real-time error correction method for binocular vision based on a fixed target array mounted on a high-stiffness foundation. A mathematical model of pose deviation is constructed incorporating thermal expansion, moisture expansion, and cross-coupling terms, and an extrinsic parameter error propagation equation under temperature–humidity disturbances is derived. An auxiliary correction camera is introduced to observe the fixed targets, and the EPnP algorithm is employed to solve for the support pose deviation, enabling dynamic compensation of the binocular system extrinsic parameters. Validation is conducted through simulations and nine sets of environmental chamber experiments, with a grating scale (accuracy: 0.5 μm) serving as the reference benchmark; the experiments cover low-temperature, high-temperature, and full-range comprehensive thermal cycling conditions. The simulation and experimental results demonstrate that the uncorrected system exhibits an average measurement error of 0.065 mm, exceeding the permissible error of 0.03 mm under all operating conditions. After applying the proposed correction method, the mean absolute error (MAE) across all conditions ranges from
0.0209 mm to0.0253 mm, with a maximum single-point error of0.0278 mm; the measurement standard deviation is substantially reduced and data repeatability is markedly enhanced, with simulation error improvement rates of 64.2%–65.8%. The proposed scheme requires only one additional correction camera and a fixed target array, without necessitating extra temperature or displacement sensors, thus offering low hardware cost and ease of integration, and is capable of satisfying the high-precision three-dimensional deformation measurement requirements for climatic strength testing of large-scale aircraft structures. -
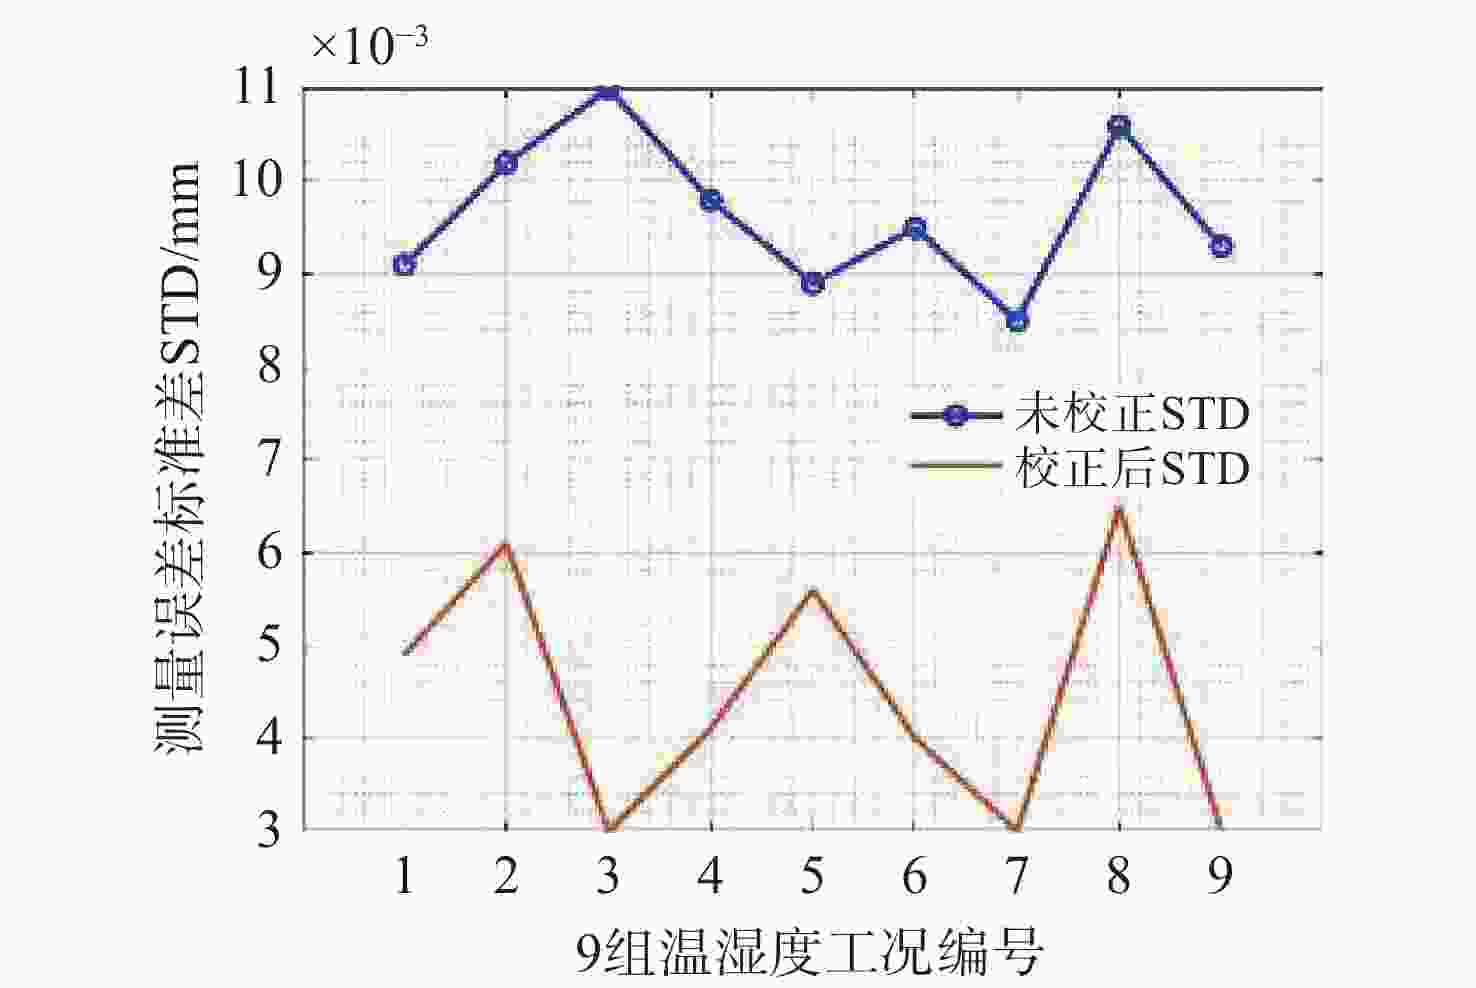
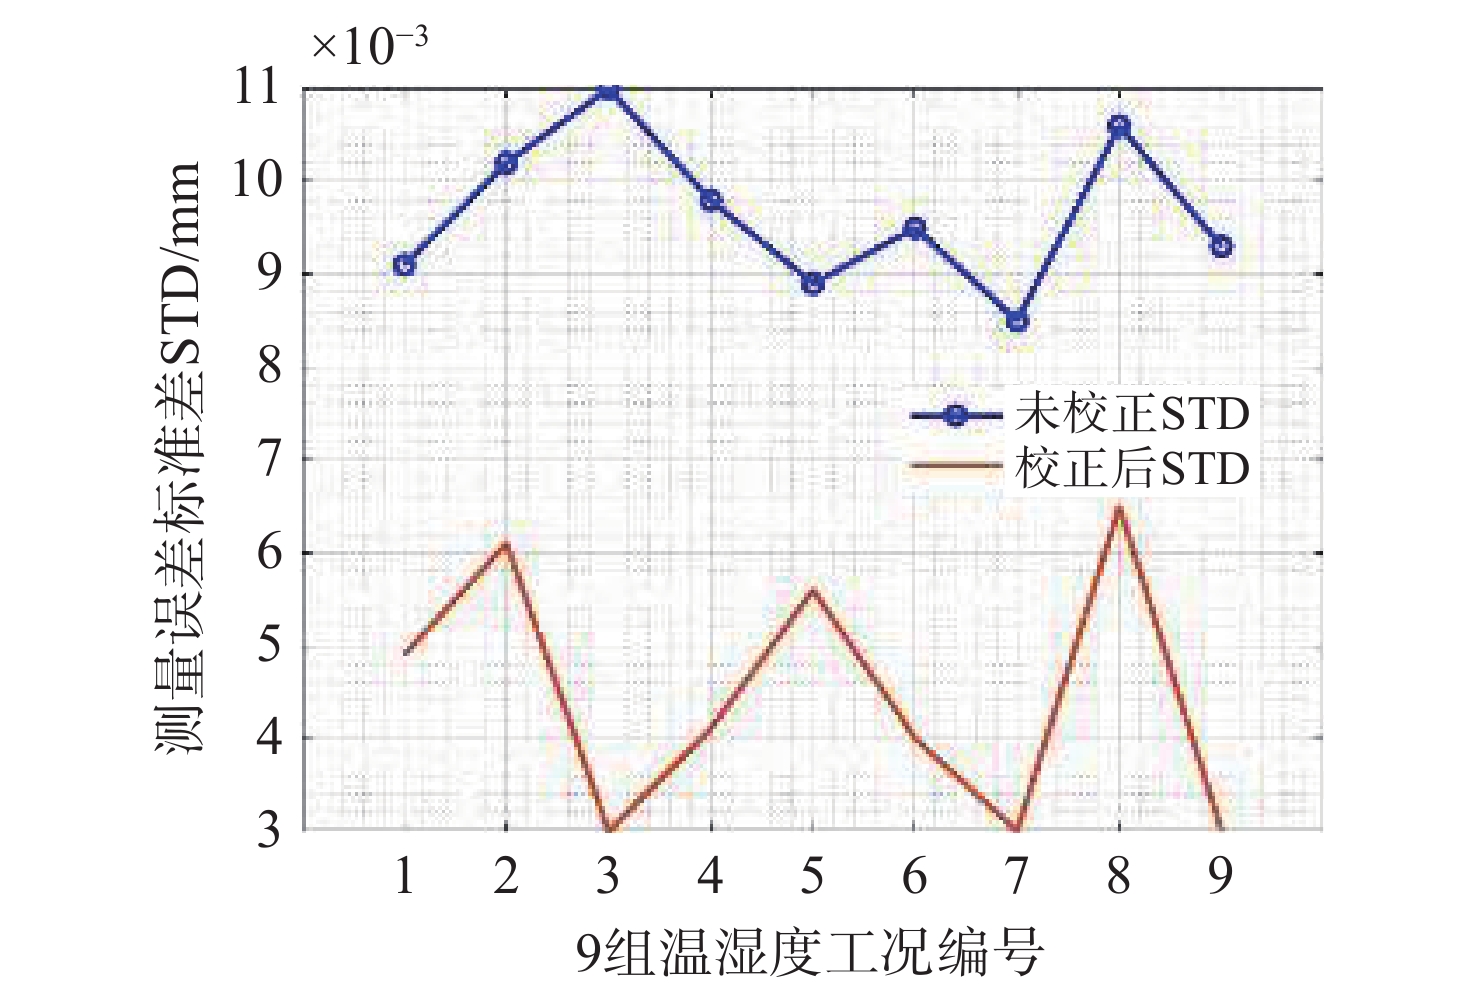
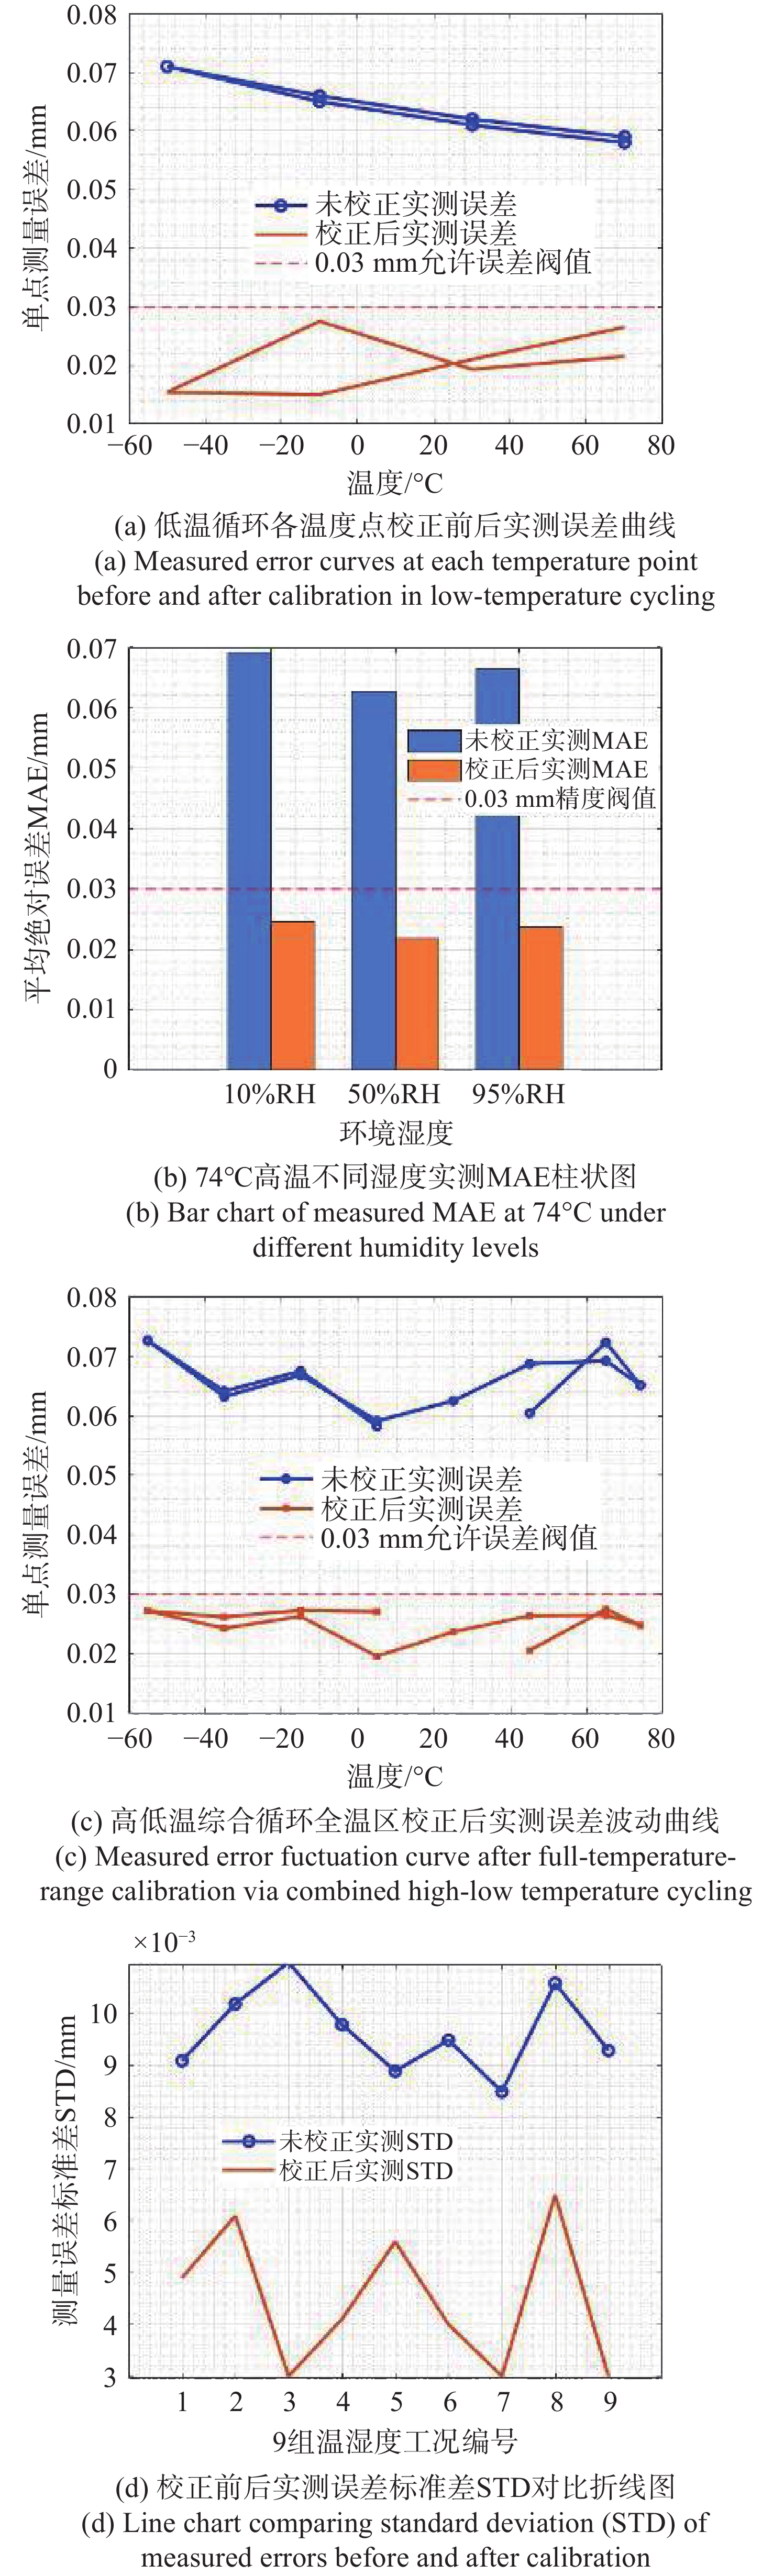
图 3 校正前后测量误差标准差STD对比折线图
Figure 3. Comparison line plot of measurement error STD before and after calibration
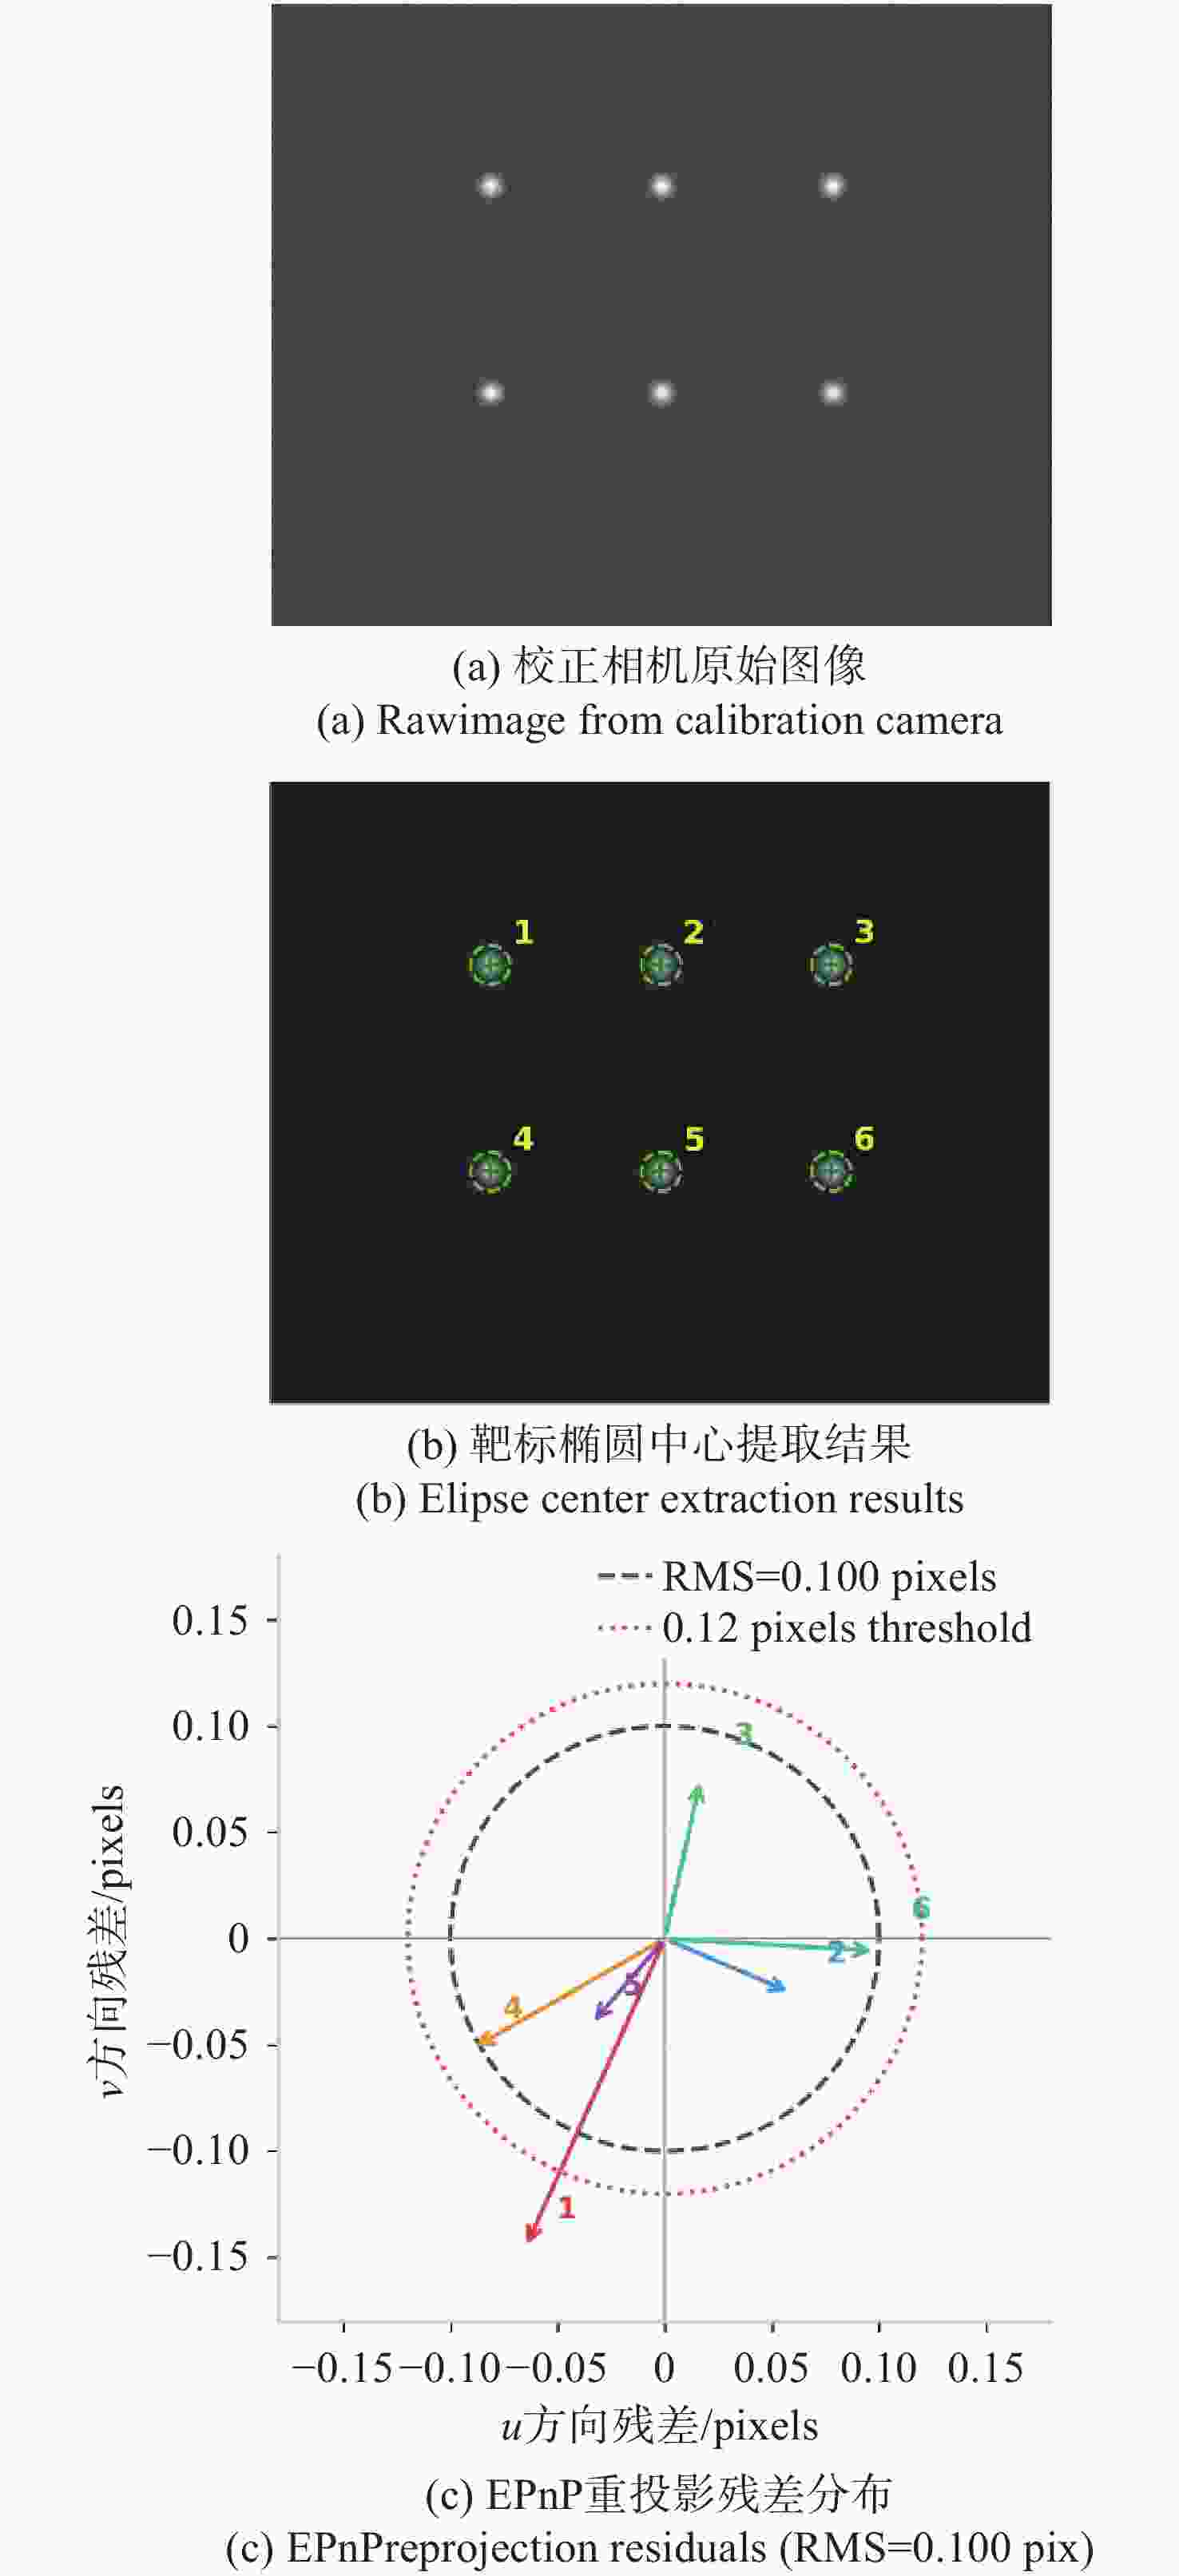
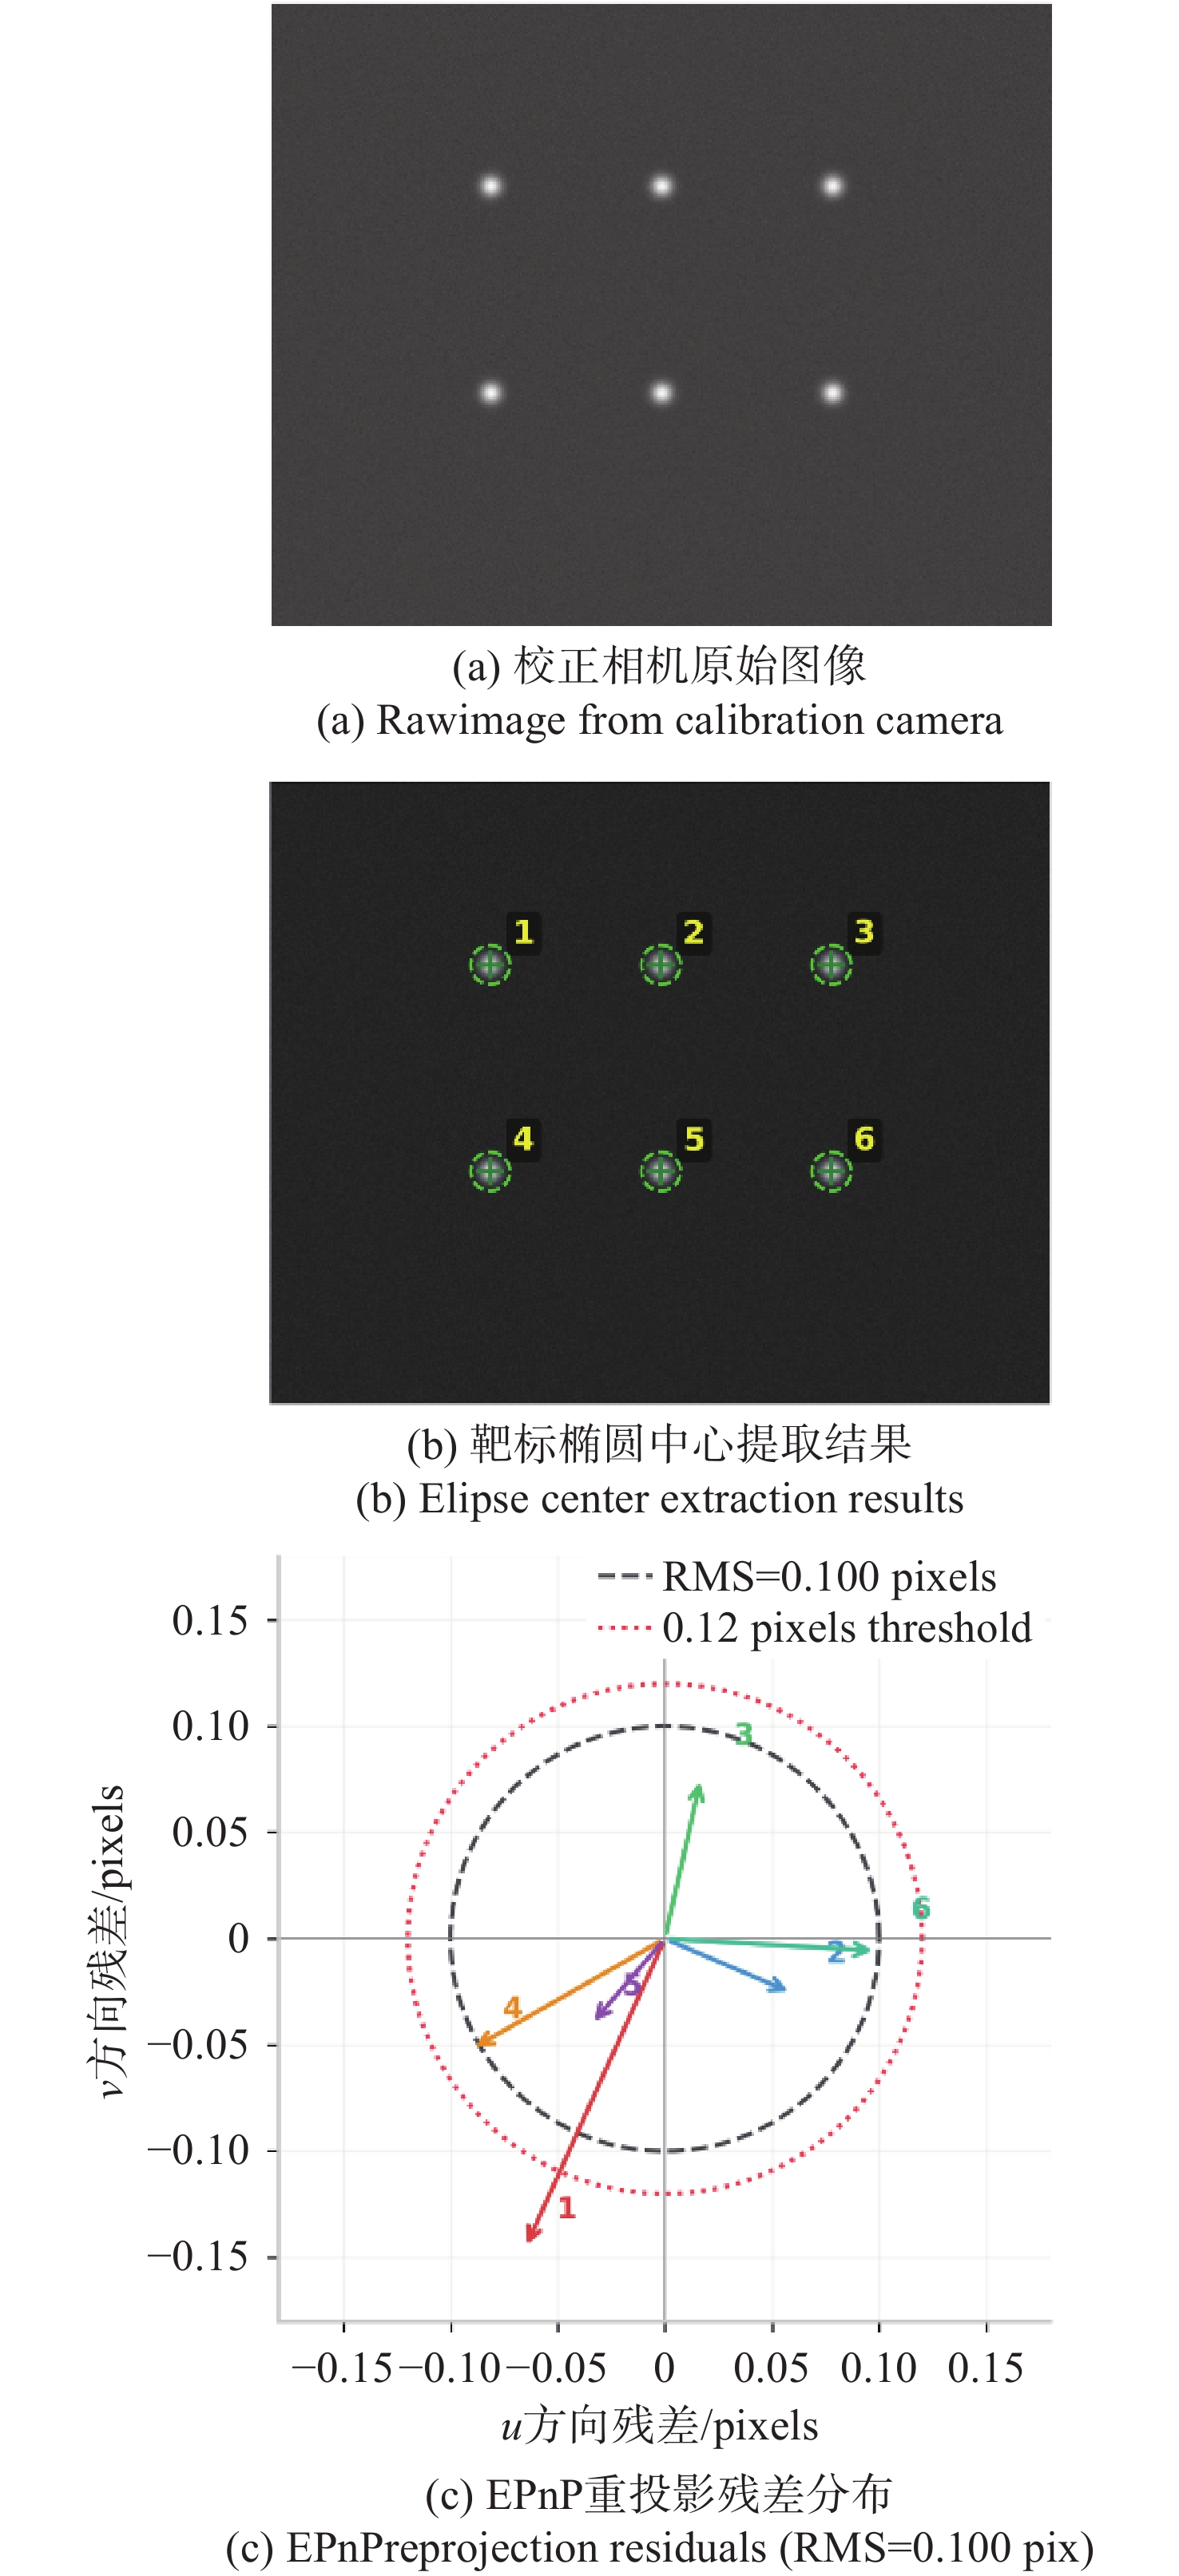
图 5 靶标检测与EPnP解算中间结果
Figure 5. Intermediate results of target detection and EPnP solving
表 1 本方法与现有方法定量对比
Table 1. Quantitative comparison between the proposed method and existing methods
方法 误差源 姿态误差界 深度误差界(Z=1 m) 外置测量法 玻璃折射、像差 / >0.1 mm IMU补偿法 零偏、温漂 0.05°~0.1° ~0.1 mm 温湿度箱防护法 局部温差、折射 / ~0.05 mm 本文方法 EPnP解算、靶标基准 0.0032 °≤ 0.0216 mm 下载: 导出CSV
表 2 校正前后仿真数据统计
Table 2. Statistics of simulation data before and after correction
工况分类 湿度 测量距离 未校正MAE(mm) 校正后MAE(mm) 误差改善率 校正后最大误差(mm) 低温循环1 10%RH 600 mm 0.0612 0.0213 65.8% 0.0279 低温循环2 15%RH 600 mm 0.0675 0.0231 65.3% 0.0278 低温循环3 20%RH 600 mm 0.0721 0.0262 64.9% 0.0272 高温循环1 10%RH 1000 mm0.0693 0.0232 64.4% 0.0279 高温循环2 50%RH 1000 mm0.0628 0.0224 65.3% 0.0269 高温循环3 95%RH 1000 mm0.0664 0.0245 64.2% 0.0275 高低温综合1 10%RH 1200 mm 0.0657 0.0231 65.1% 0.0276 高低温综合2 15%RH 1200 mm 0.0622 0.0246 64.9% 0.0282 高低温综合3 20%RH 1200 mm0.0669 0.0257 65.8% 0.0277
下载: 导出CSV
表 3 实验系统硬件配置
Table 3. Hardware setup of the experimental system
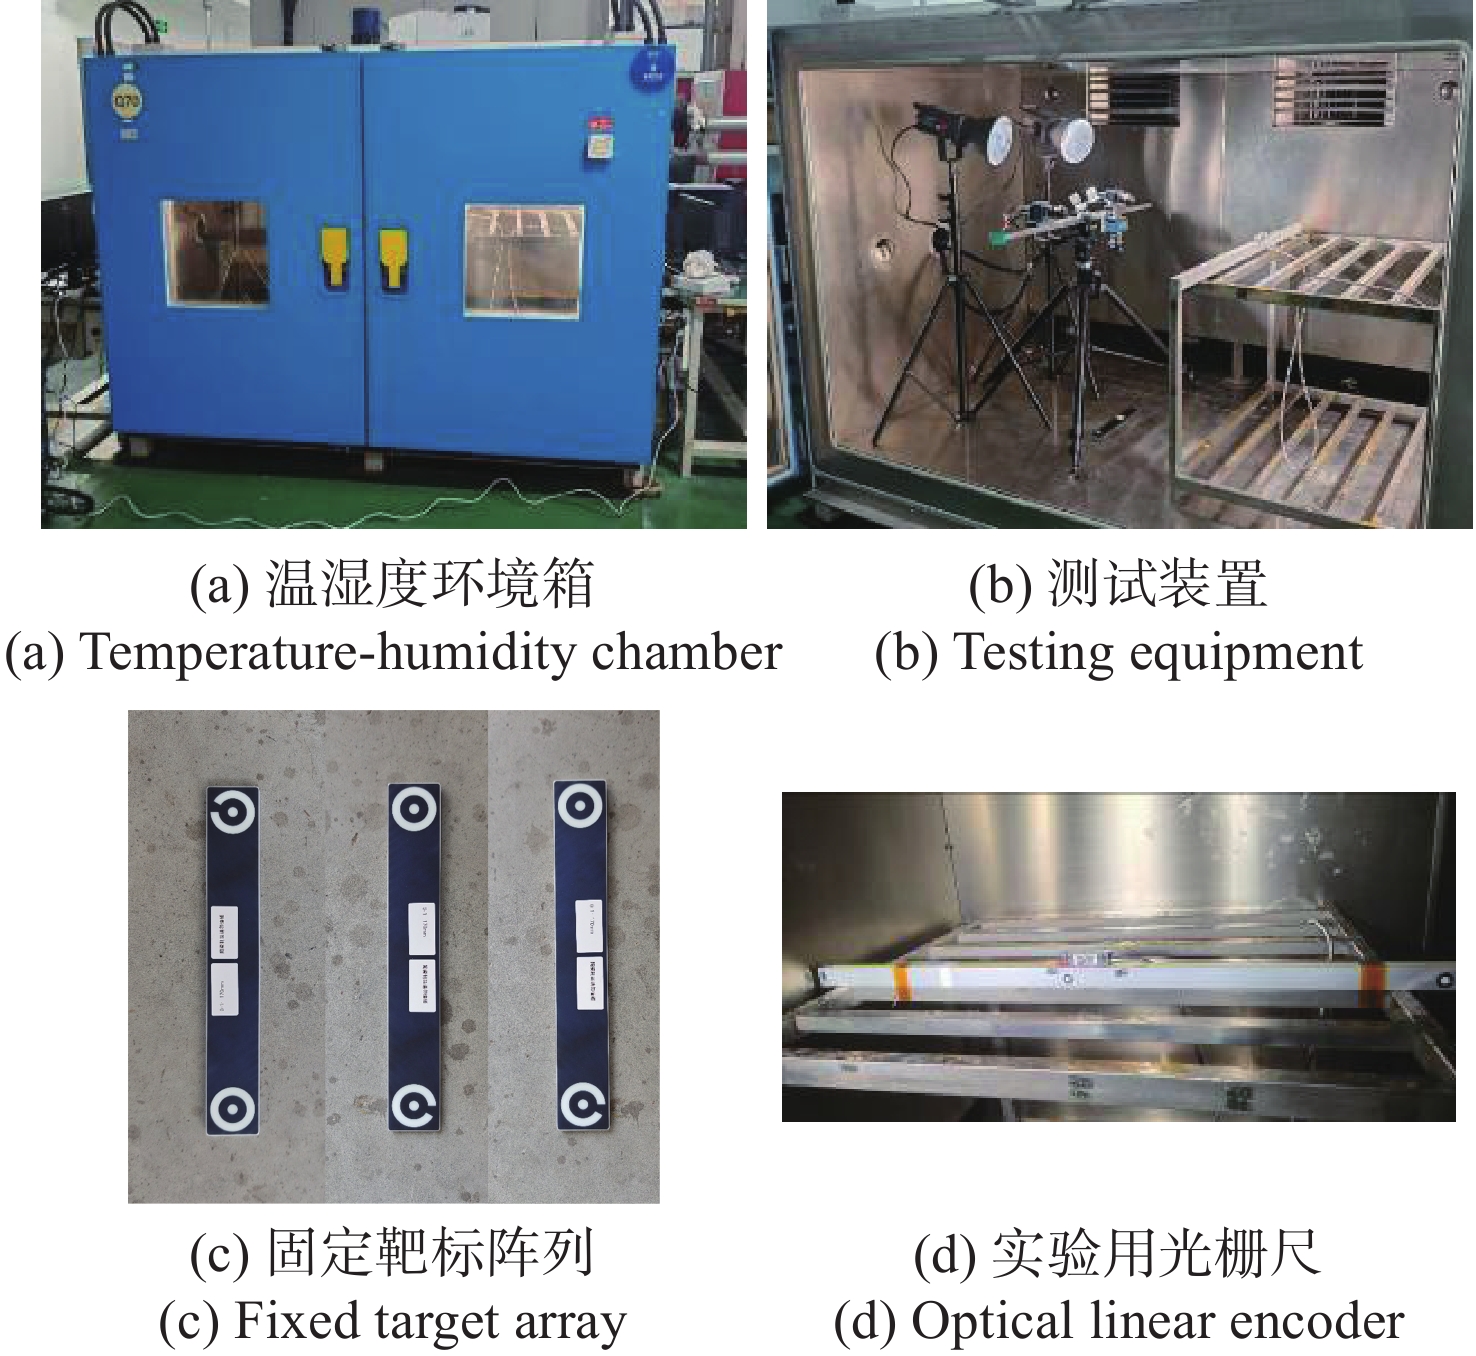
序号 名称 数量 作用 1 抗高低温工业相机( 5120 ×5120 像素)3套 成像(双目2套+校正1套) 2 抗高低温工业镜头(50 mm/12 mm) 3套 成像(双目50 mm+校正12 mm) 3 10GigE抗高低温线缆 3套 信号传输 4 光源 2个 增加被测区光强
下载: 导出CSV
表 4 靶标阵列基准坐标
Table 4. Reference coordinates of target array
靶标编号 XW (mm) YW (mm) ZW (mm) 1 0.000 0.000 0.000 2 300.015 0.008 0.003 3 600.022 −0.005 0.006 4 −0.003 200.012 0.002 5 300.018 200.009 −0.004 6 600.025 199.995 0.001
下载: 导出CSV
-
[1] ZHANG Z. A flexible new technique for camera calibration[J]. IEEE Transactions on Pattern Analysis and Machine Intelligence, 2000, 22(11): 1330-1334. doi: 10.1109/34.888718 [2] HARTLEY R, ZISSERMAN A. Multiple View Geometry in Computer Vision[M]. 2nd ed. Cambridge: Cambridge University Press, 2003. [3] ZHAO H W, MA W H, JI P R, et al. Modeling the measurement accuracy for binocular stereo vision system[J]. Optics Express, 2025, 33(9): 19051-19066. doi: 10.1364/OE.547550 [4] MIL-STD-810H Method 501.7 — High temperature[S]. US Department of Defense, 2019. (查阅网上资料, 未找到本条文献作者和出版信息, 请确认). [5] ADAMCZYK M, LIBERADZKI P, SITNIK R. Temperature compensation method for digital cameras in 2D and 3D measurement applications[J]. Sensors, 2018, 18(11): 3685. doi: 10.3390/s18113685 [6] PAN B, SHI W T, LUBINEAU G. Effect of camera temperature variations on stereo-digital image correlation measurements[J]. Applied Optics, 2015, 54(34): 10089-10095. doi: 10.1364/AO.54.010089 [7] CHIU M Y, CHEN G CH, HSU T H, et al. A multimode vision sensor with temporal contrast pixel and column-parallel local binary pattern extraction for dynamic depth sensing using stereo vision[J]. IEEE Journal of Solid-State Circuits, 2023, 58(10): 2767-2777. doi: 10.1109/JSSC.2023.3292051 [8] 吴大方, 王怀涛, 朱芳卉. 1200 °C高温环境下部件受热前表面应变的光学测量[J]. 应用数学和力学, 2018, 39(6): 631-644.WU D F, WANG H T, ZHU F H. Optical measurement of heated-front-surface strains for components in high temperature environments up to 1200 °C[J]. Applied Mathematics and Mechanics, 2018, 39(6): 631-644. (in Chinese). [9] 申旭. 卫星天线高低温热变形测量技术综述[J]. 航天器环境工程, 2022, 39(3): 306-315. doi: 10.12126/see.2022.03.014SHEN X. Review of technologies for measuring thermal deformation of satellite antenna at high and low temperatures[J]. Spacecraft Environment Engineering, 2022, 39(3): 306-315. (in Chinese). doi: 10.12126/see.2022.03.014 [10] ELAMIN A, EL-RABBANY A. Event/visual/IMU integration for UAV-based indoor navigation[J]. Proceedings, 2024, 110(1): 2. [11] GUO D, LI N N, FANG CH SH, et al. Fast and highly accurate registration of textile double-sided images: an innovative solution for the calibration of binocular measuring systems[J]. Measurement, 2025, 245: 116539. doi: 10.1016/j.measurement.2024.116539 [12] ZHAO Y, LI W M. Self-calibration of a binocular vision system based on a one-dimensional target[J]. Journal of Modern Optics, 2014, 61(18): 1529-1537. doi: 10.1080/09500340.2014.944233 [13] ZHANG ZH Y. Flexible camera calibration by viewing a plane from unknown orientations[C]. Proceedings of the Seventh IEEE International Conference on Computer Vision, IEEE, 1999: 666-673. [14] HOU CH CH, KANG Y F, QIAO T ZH. Multi-camera hierarchical calibration and three-dimensional reconstruction method for bulk material transportation system[J]. Sensors, 2025, 25(7): 2111. doi: 10.3390/s25072111 [15] SCHARSTEIN D, SZELISKI R. A taxonomy and evaluation of dense two-frame stereo correspondence algorithms[J]. International Journal of Computer Vision, 2002, 47(1-3): 7-42. doi: 10.1023/A:1014573219977 [16] YANG W K, WANG Z J, XU J, et al. Ultracompact computational spectroscopy with a detour-phased planar lens[J]. Light: Advanced Manufacturing, 2024, 5(4): 523-531. doi: 10.37188/lam.2024.044 [17] ZHANG Y R, YANG E B, YOON H H, et al. Reconstructive spectrometers: hardware miniaturization and computational reconstruction[J]. eLight, 2025, 5(1): 23. doi: 10.1186/s43593-025-00101-0 [18] TRUCCO E, VERRI A. Introductory Techniques for 3-D Computer Vision[M]. Upper Saddle River: Prentice Hall PTR, 1998. [19] CALLISTER W D, RETHWISCH D G. Materials Science and Engineering: An Introduction[M]. 9th ed. Hoboken: Wiley, 2014. [20] YU L P, LUBINEAU G. Modeling of systematic errors in stereo-digital image correlation due to camera self-heating[J]. Scientific Reports, 2019, 9(1): 6567. doi: 10.1038/s41598-019-43019-7 [21] LEPETIT V, MORENO-NOGUER F, FUA P. EPnP: an accurate O(n) solution to the PnP problem[J]. International Journal of Computer Vision, 2009, 81(2): 155-166. doi: 10.1007/s11263-008-0152-6 [22] GAO X SH, HOU X R, TANG J L, et al. Complete solution classification for the perspective-three-point problem[J]. IEEE Transactions on Pattern Analysis and Machine Intelligence, 2003, 25(8): 930-943. doi: 10.1109/TPAMI.2003.1217599 [23] 汪佳宝, 张世荣, 周清雅. 基于视觉EPnP加权迭代算法的三维位移实时测量[J]. 仪器仪表学报, 2020, 41(2): 166-175. doi: 10.19650/j.cnki.cjsi.J1905952WANG J B, ZHANG SH R, ZHOU Q Y. Vision based real-time 3D displacement measurement using weighted iterative EPnP algorithm[J]. Chinese Journal of Scientific Instrument, 2020, 41(2): 166-175. (in Chinese). doi: 10.19650/j.cnki.cjsi.J1905952 -

 下载:

计量
- 文章访问数: 2
- HTML全文浏览量: 1
- PDF下载量: 0
- 被引次数: 0
